Meta Reality Labs
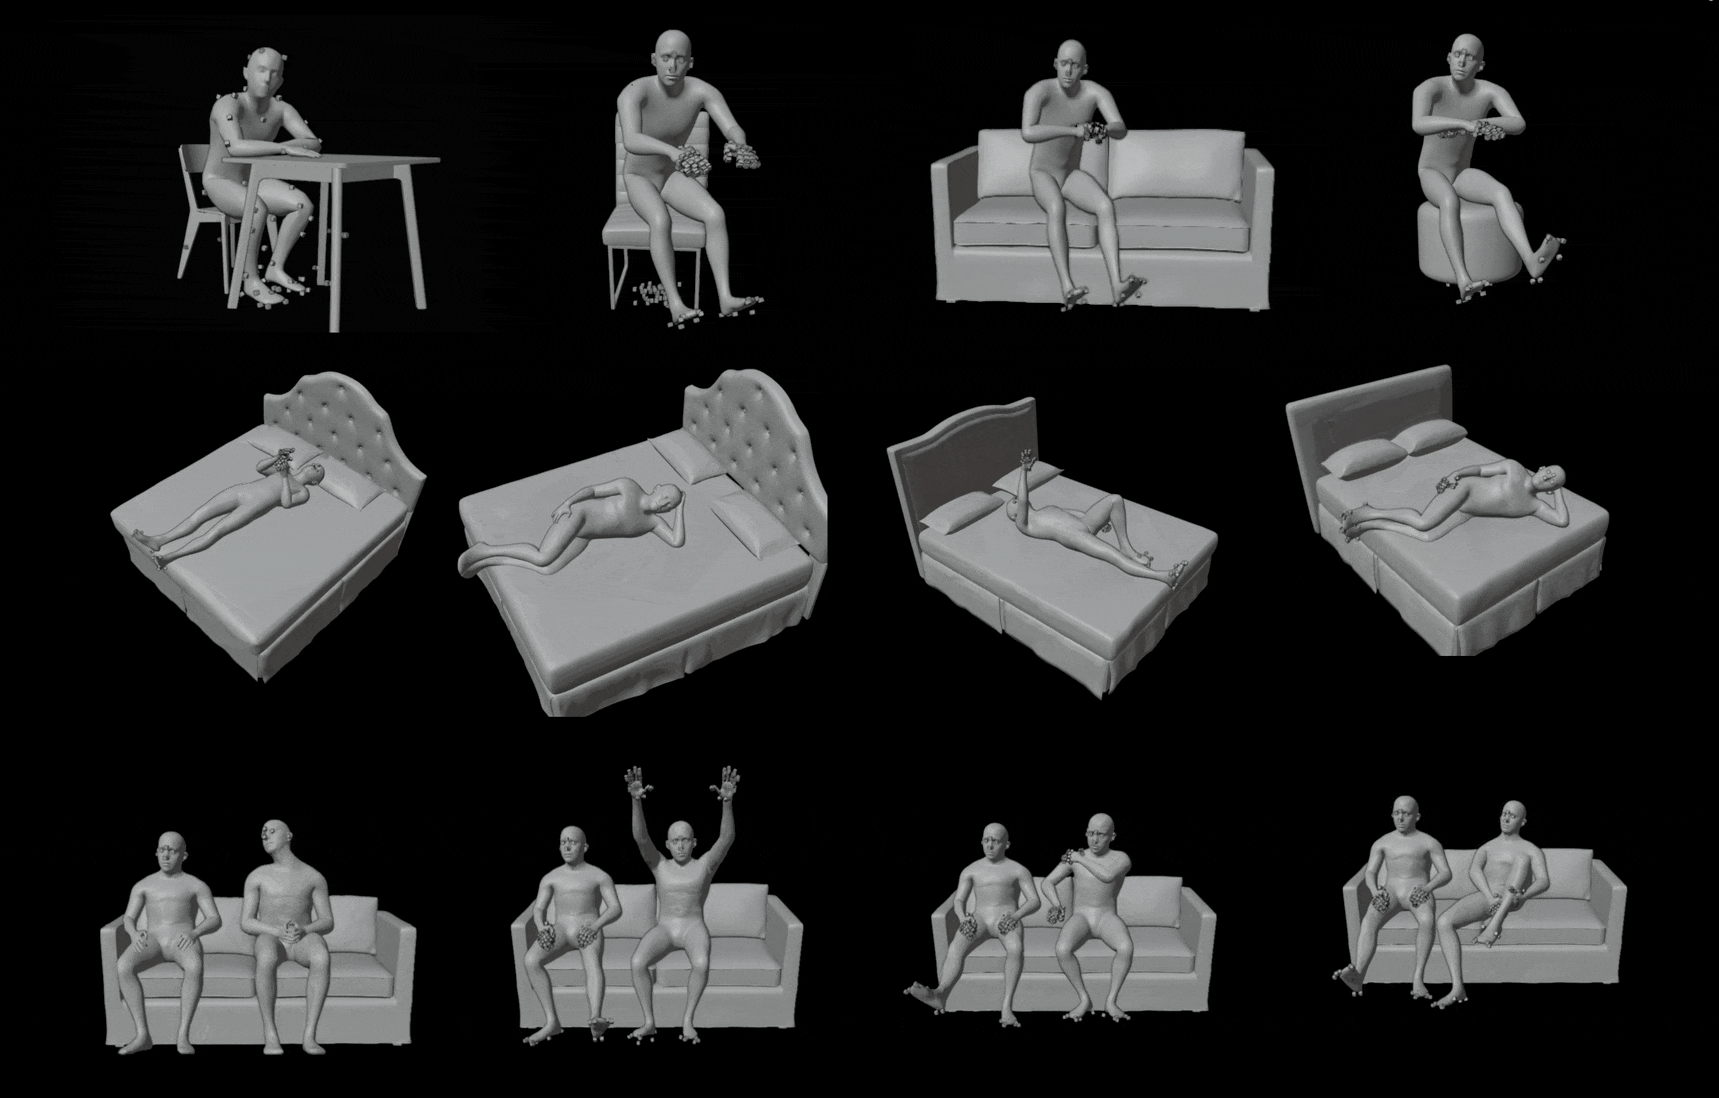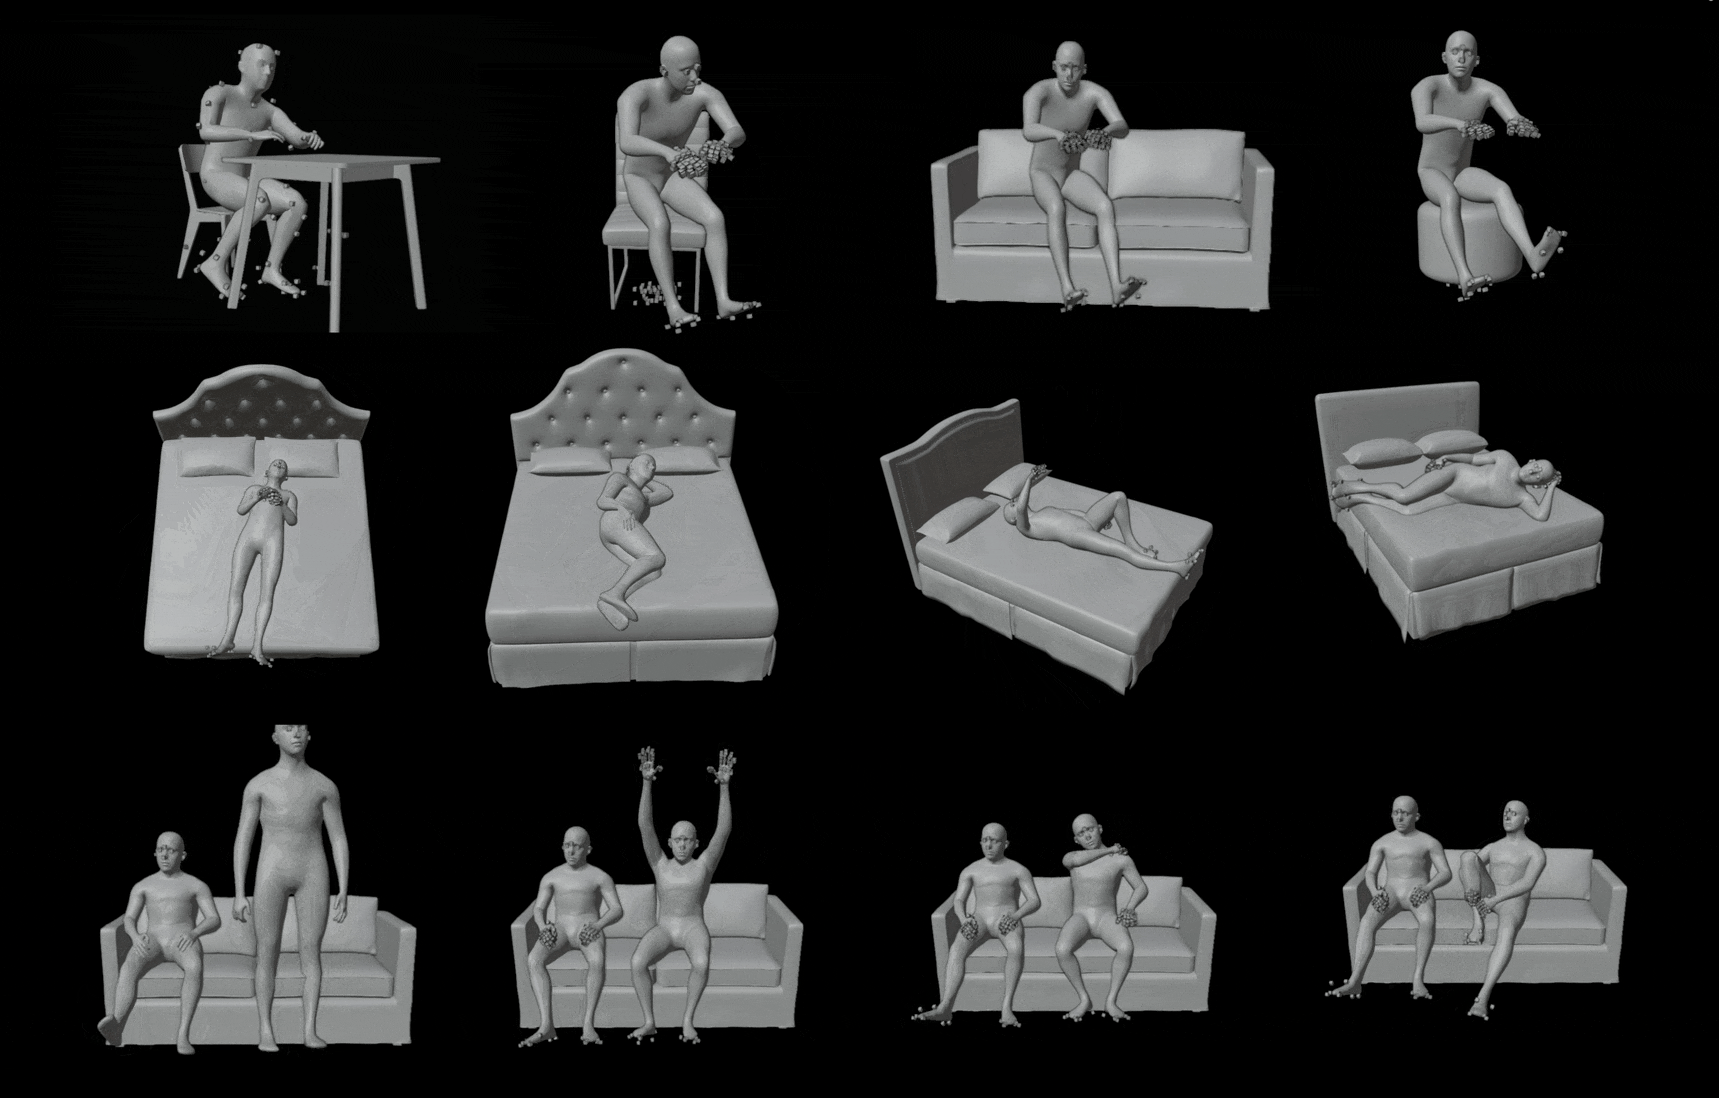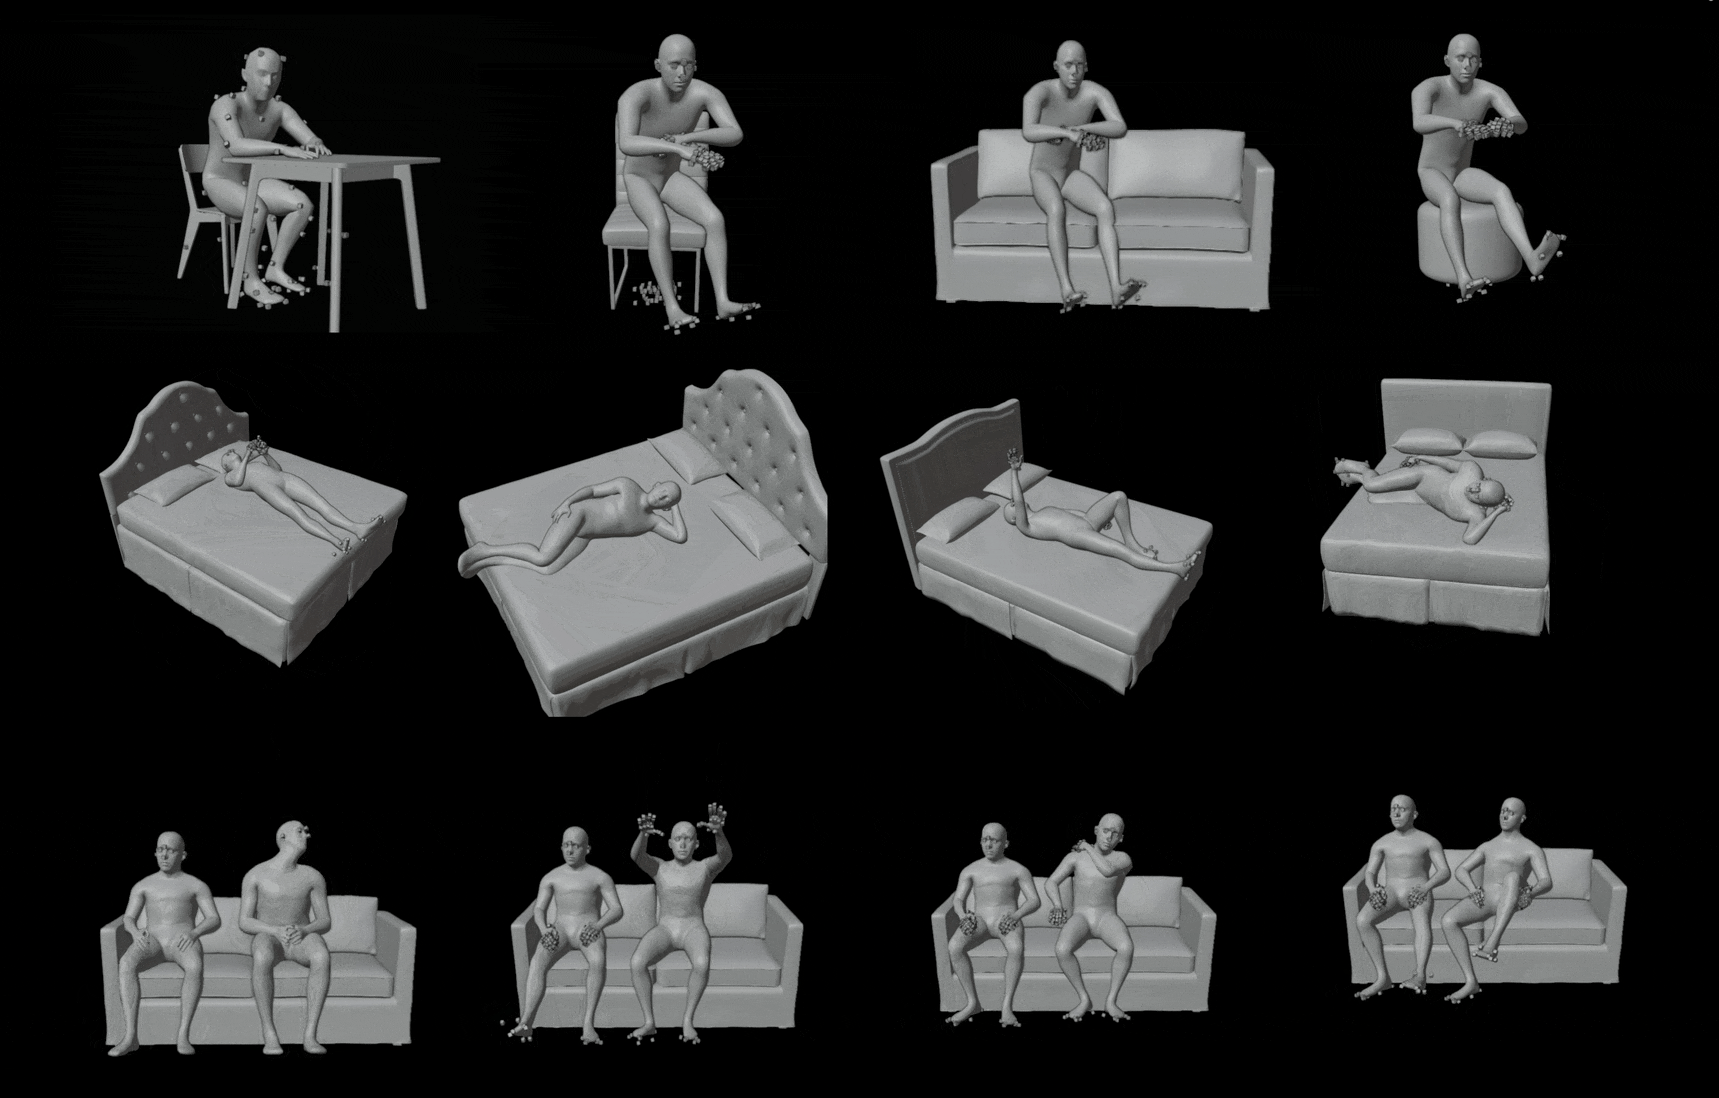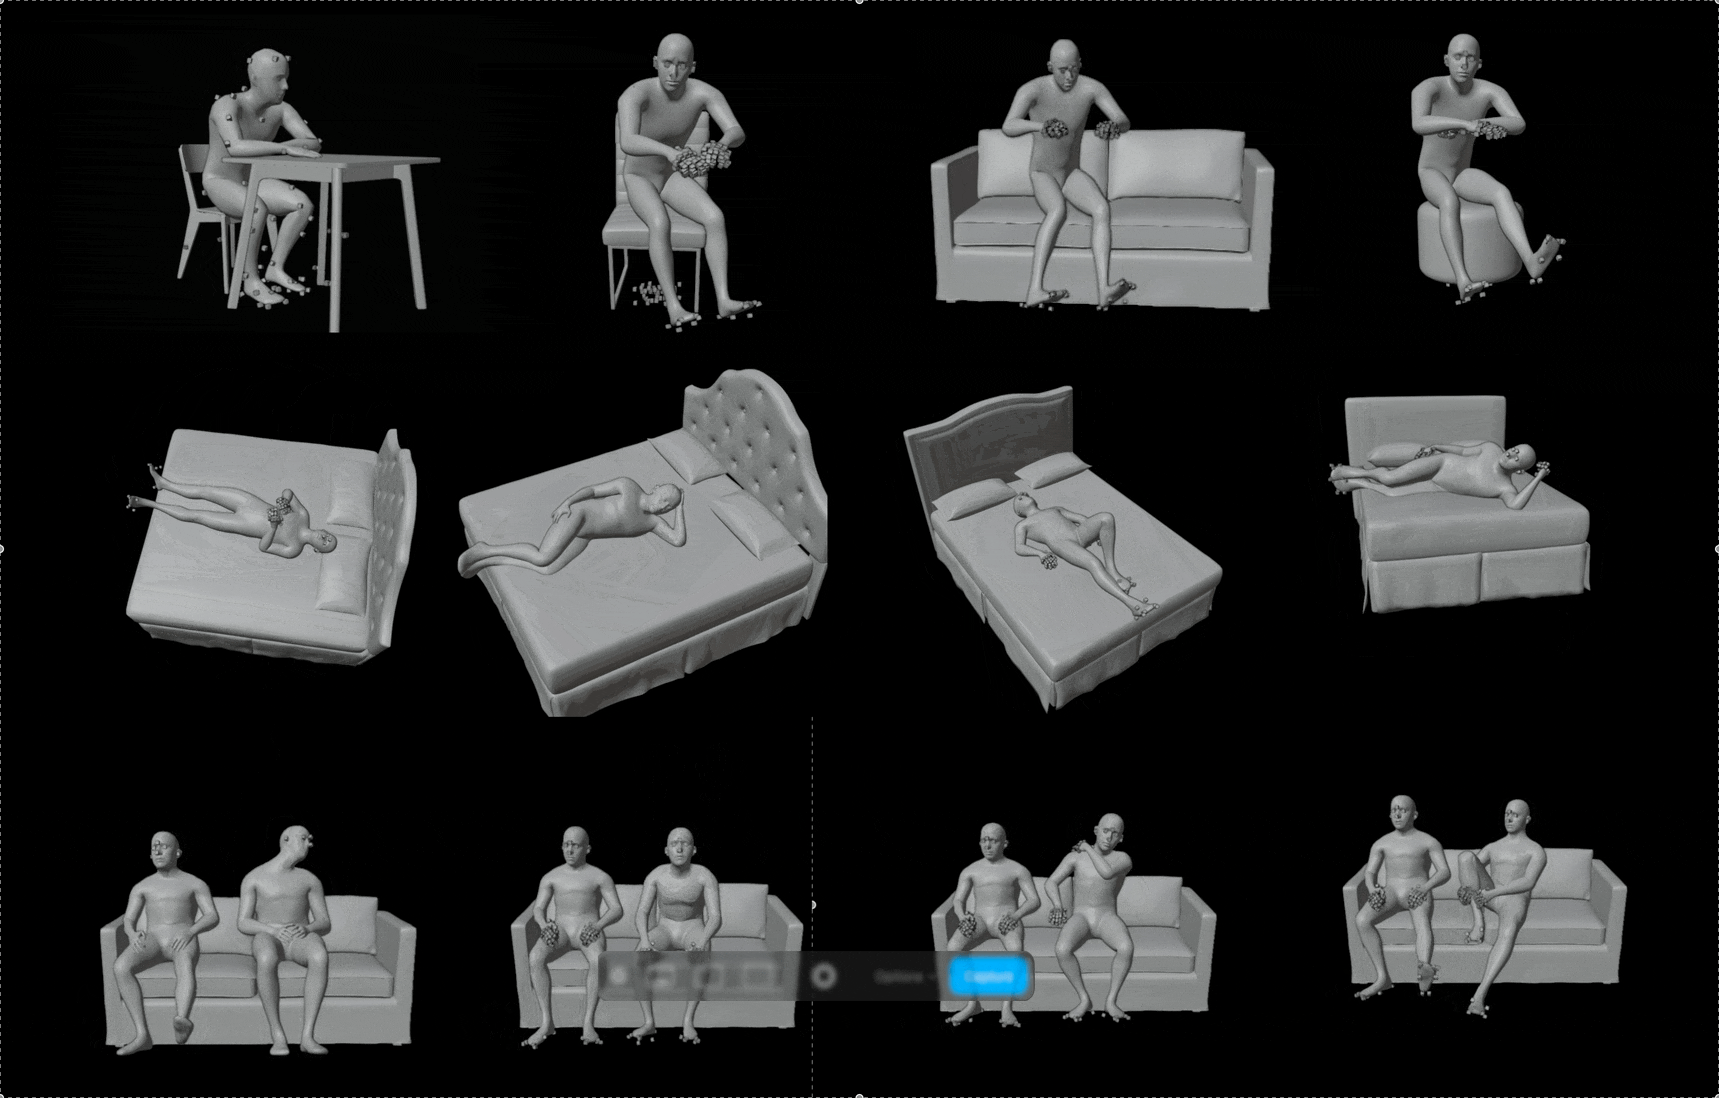
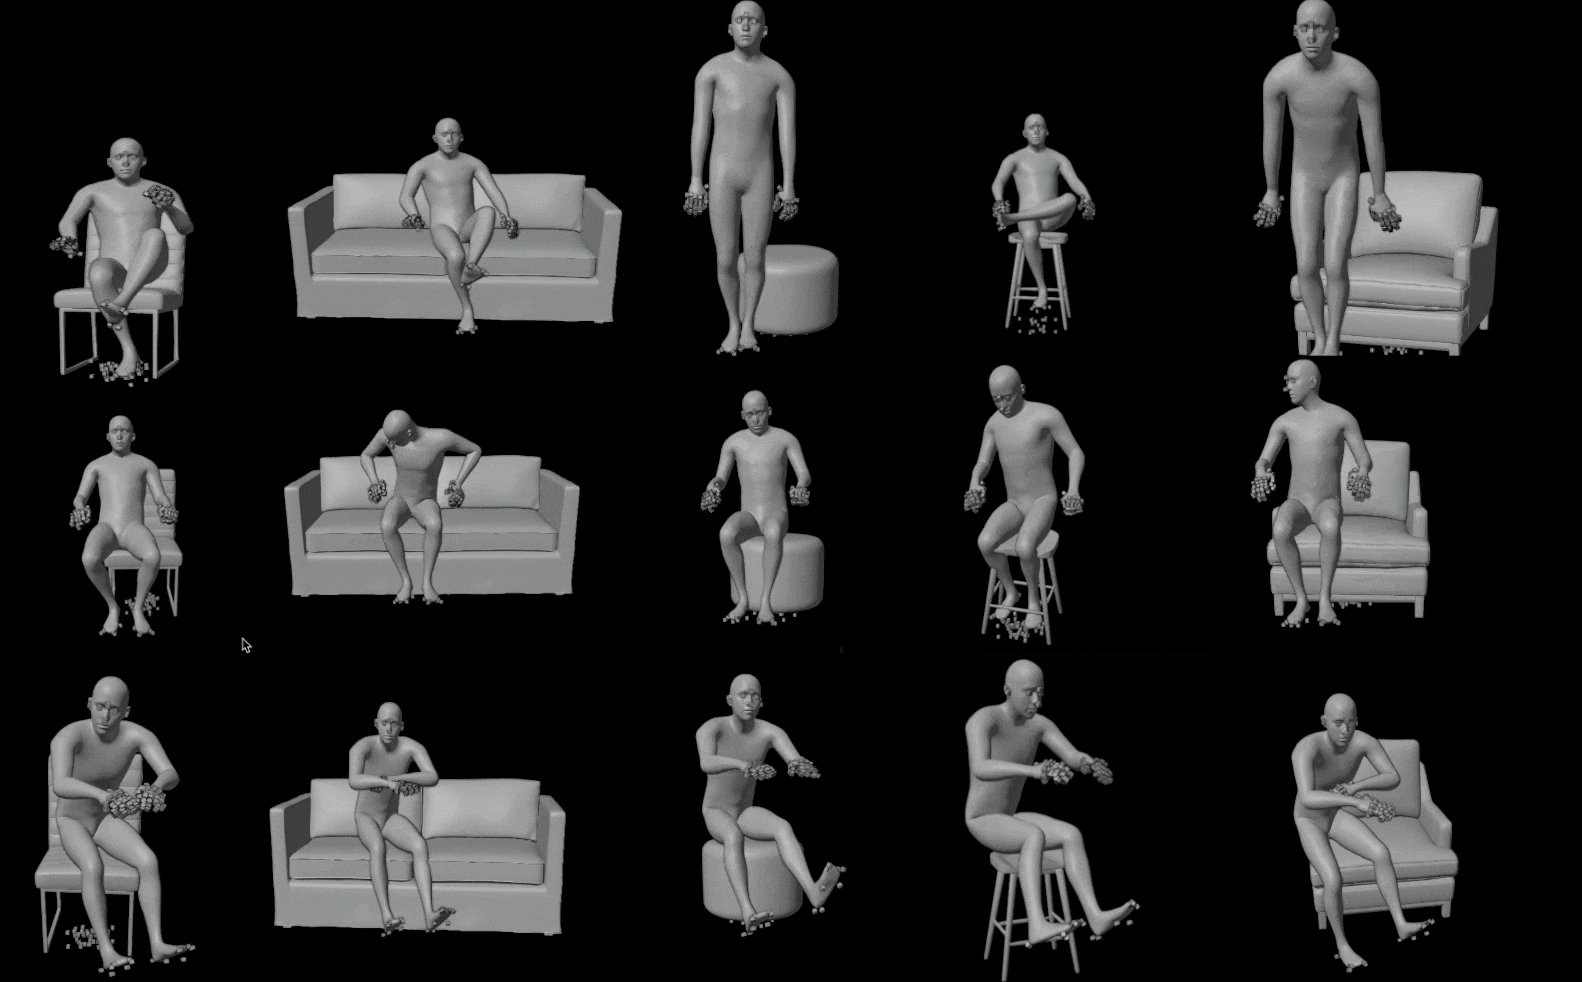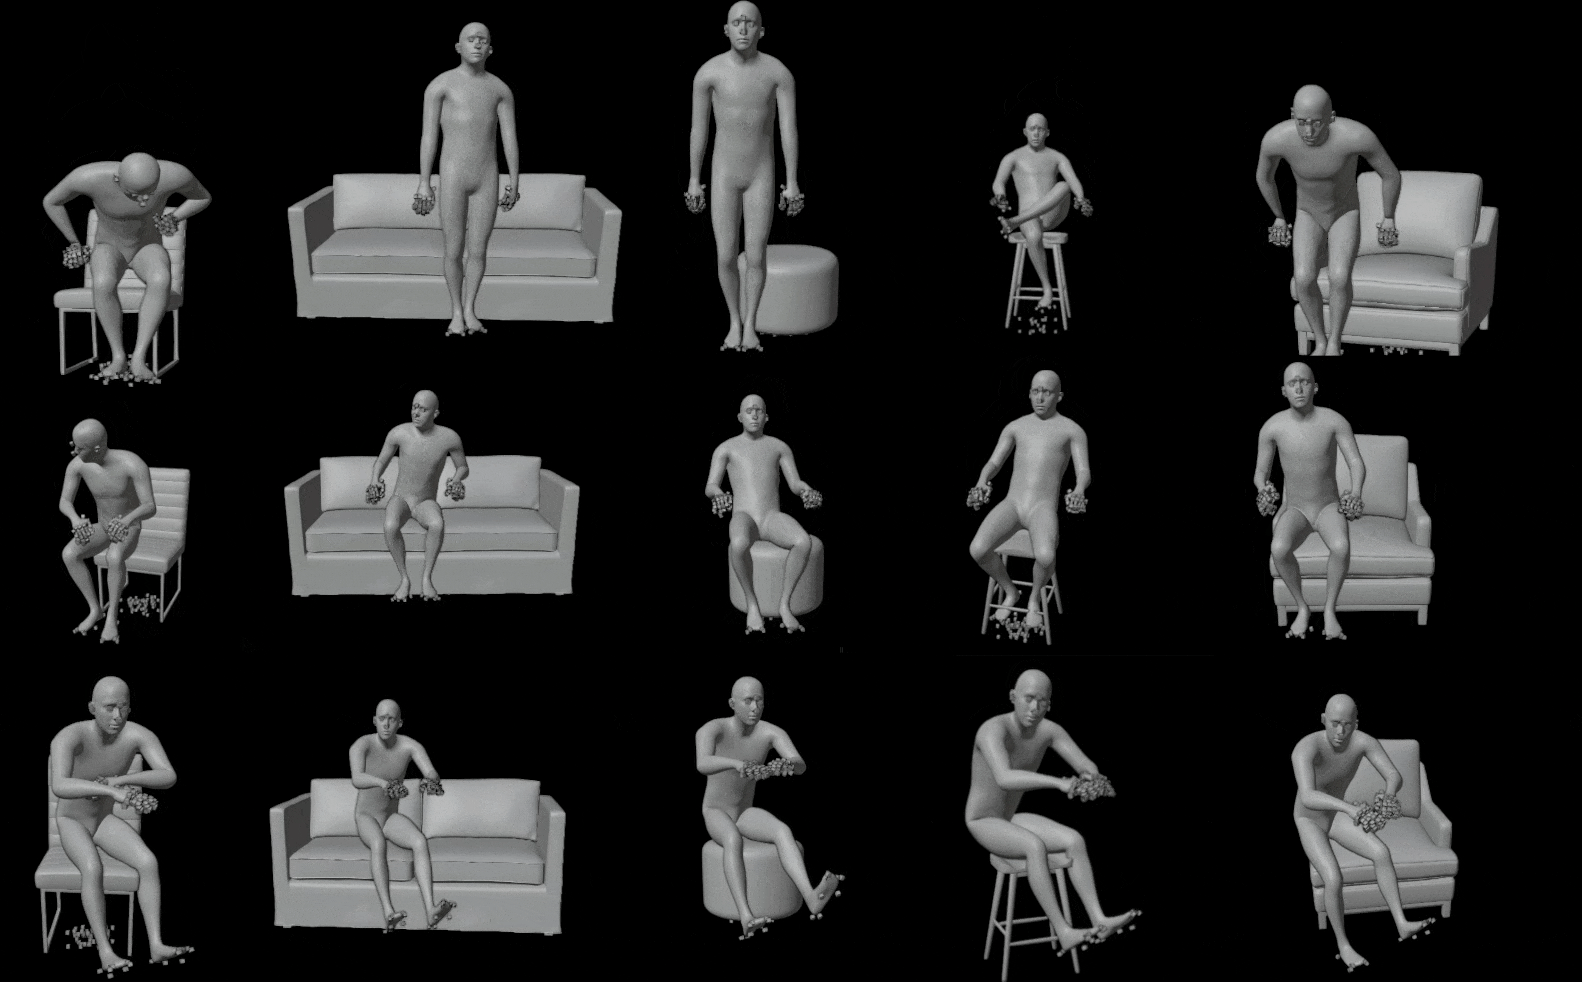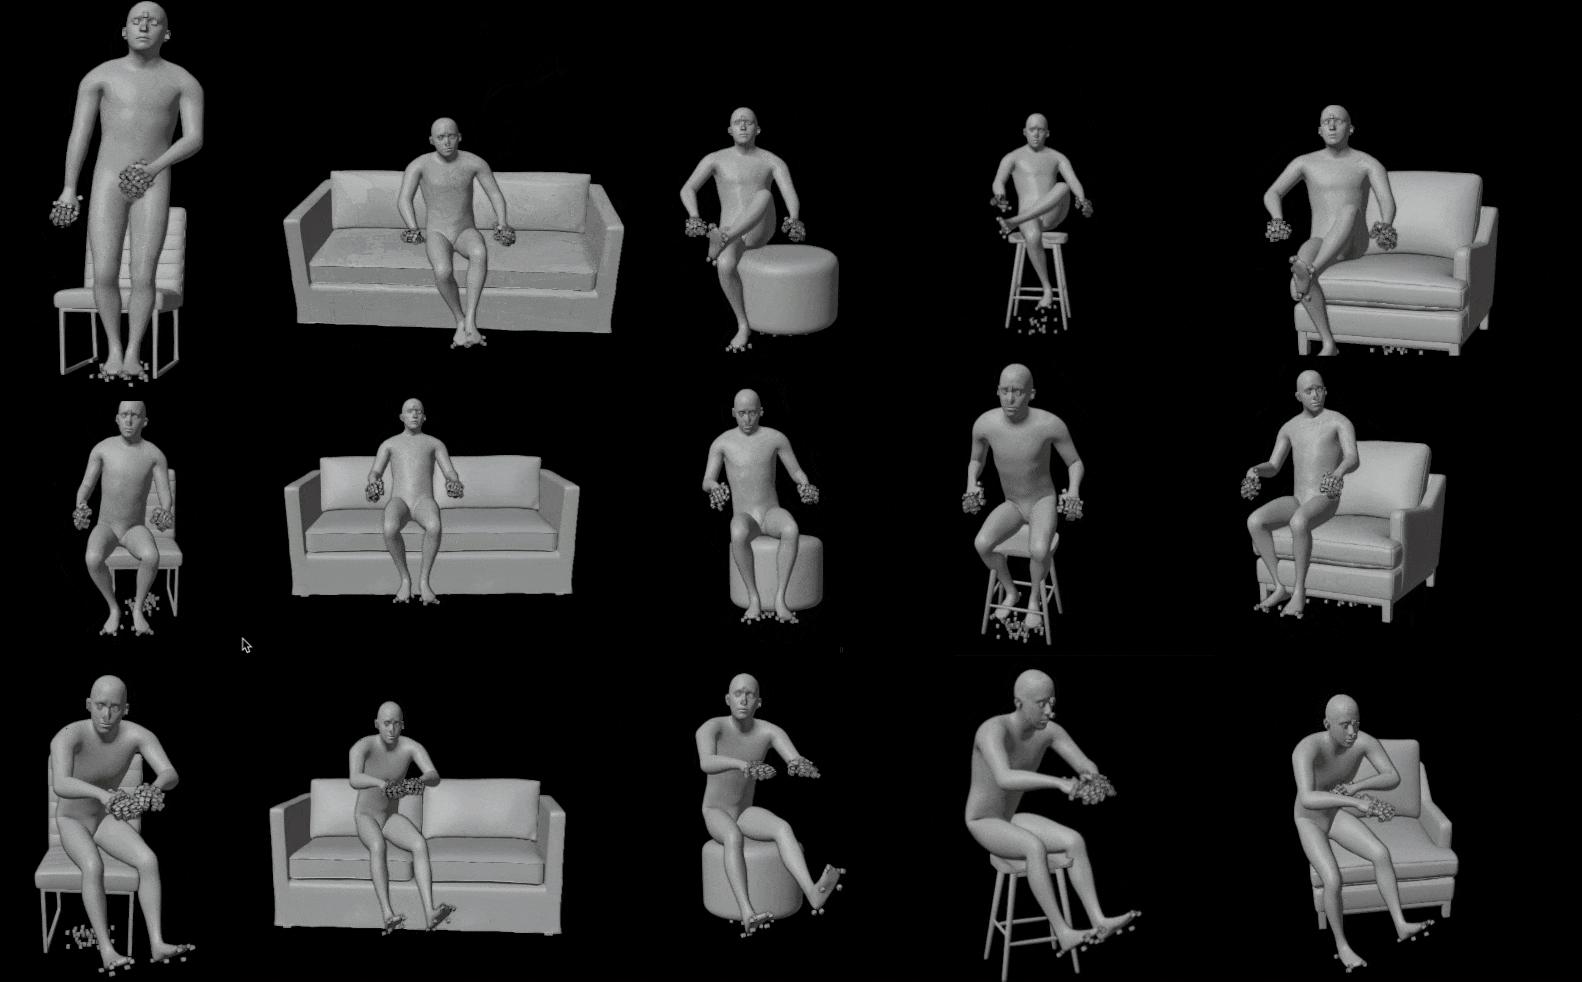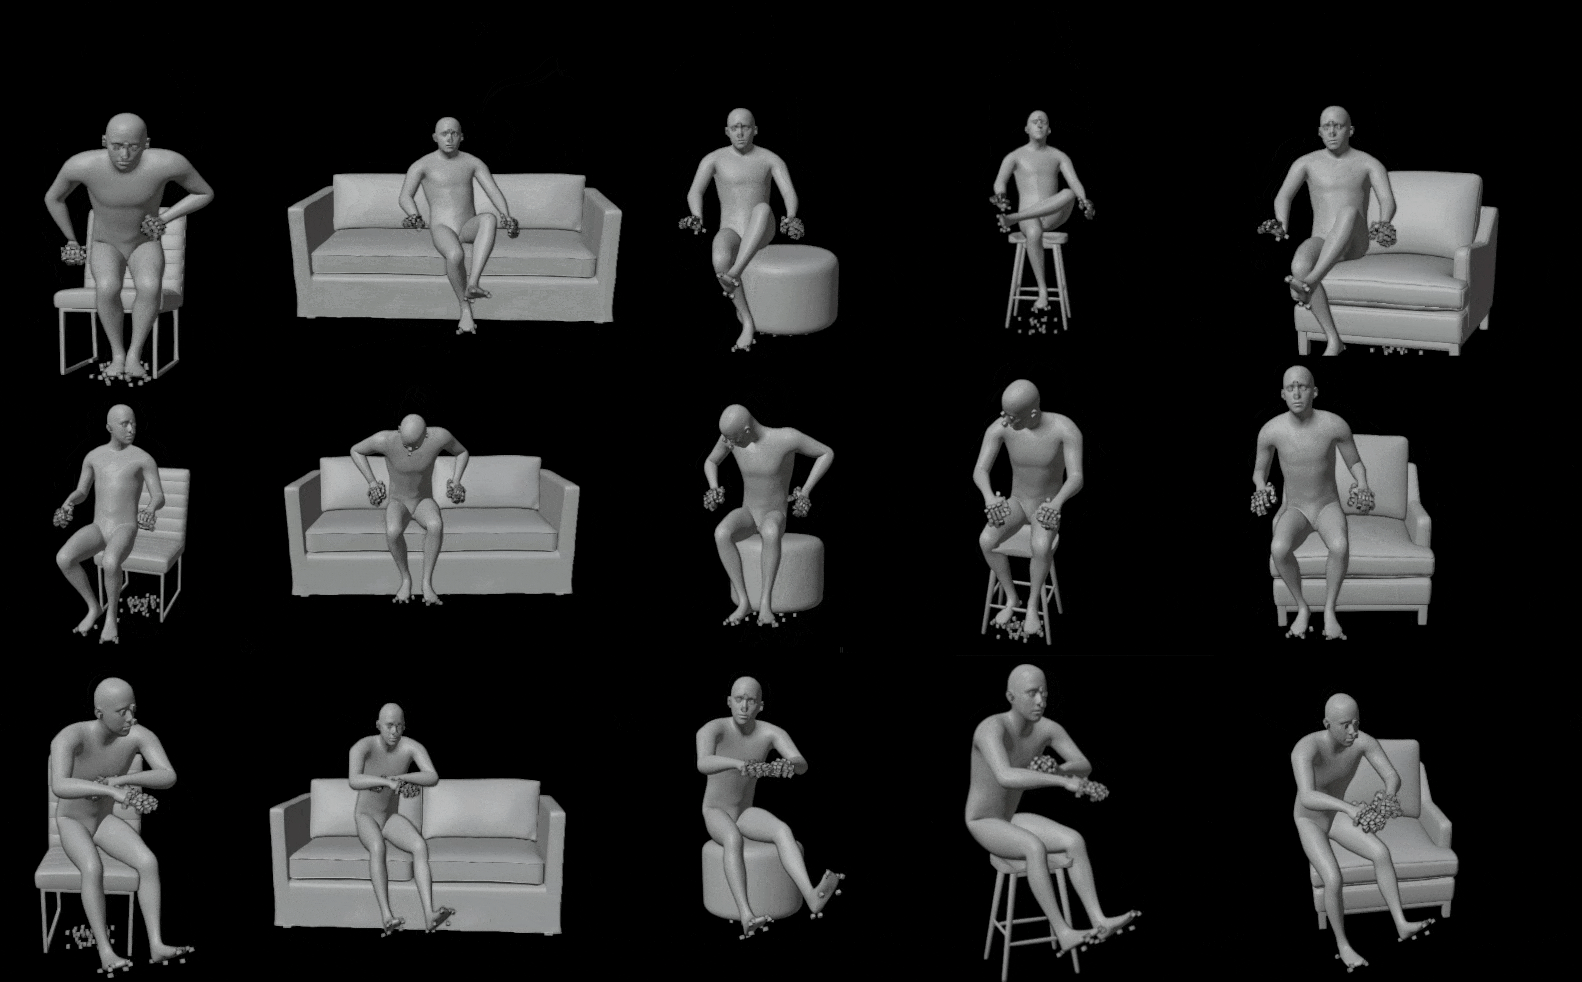
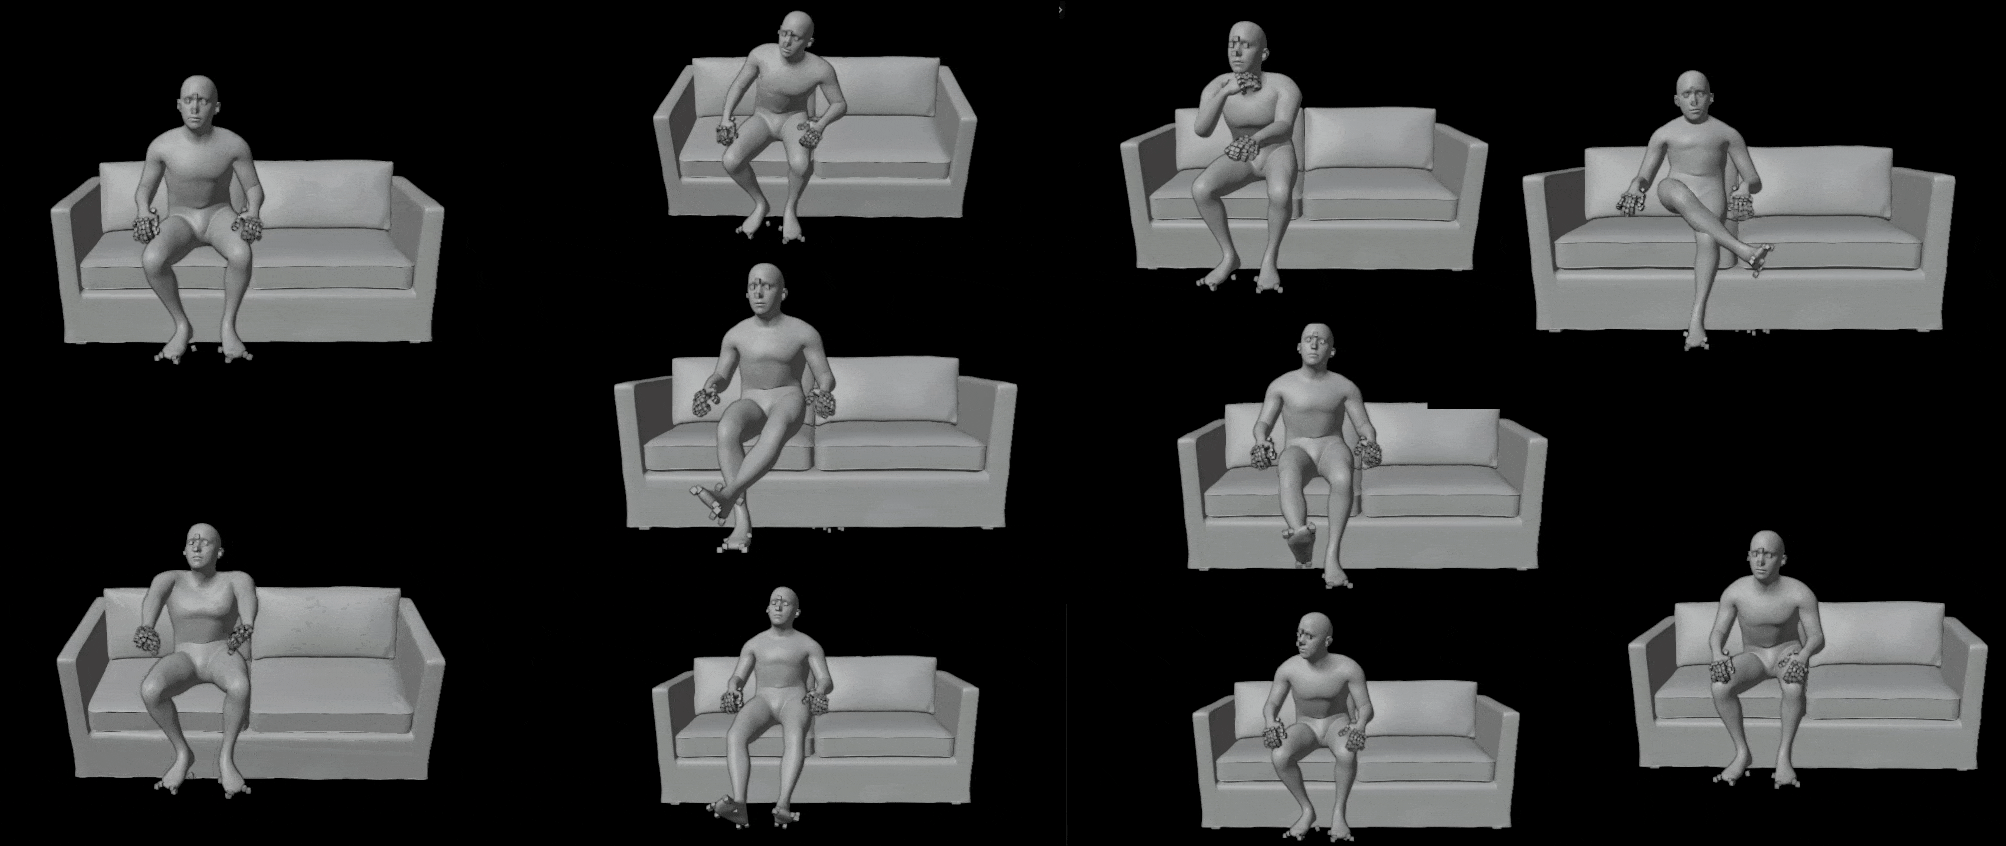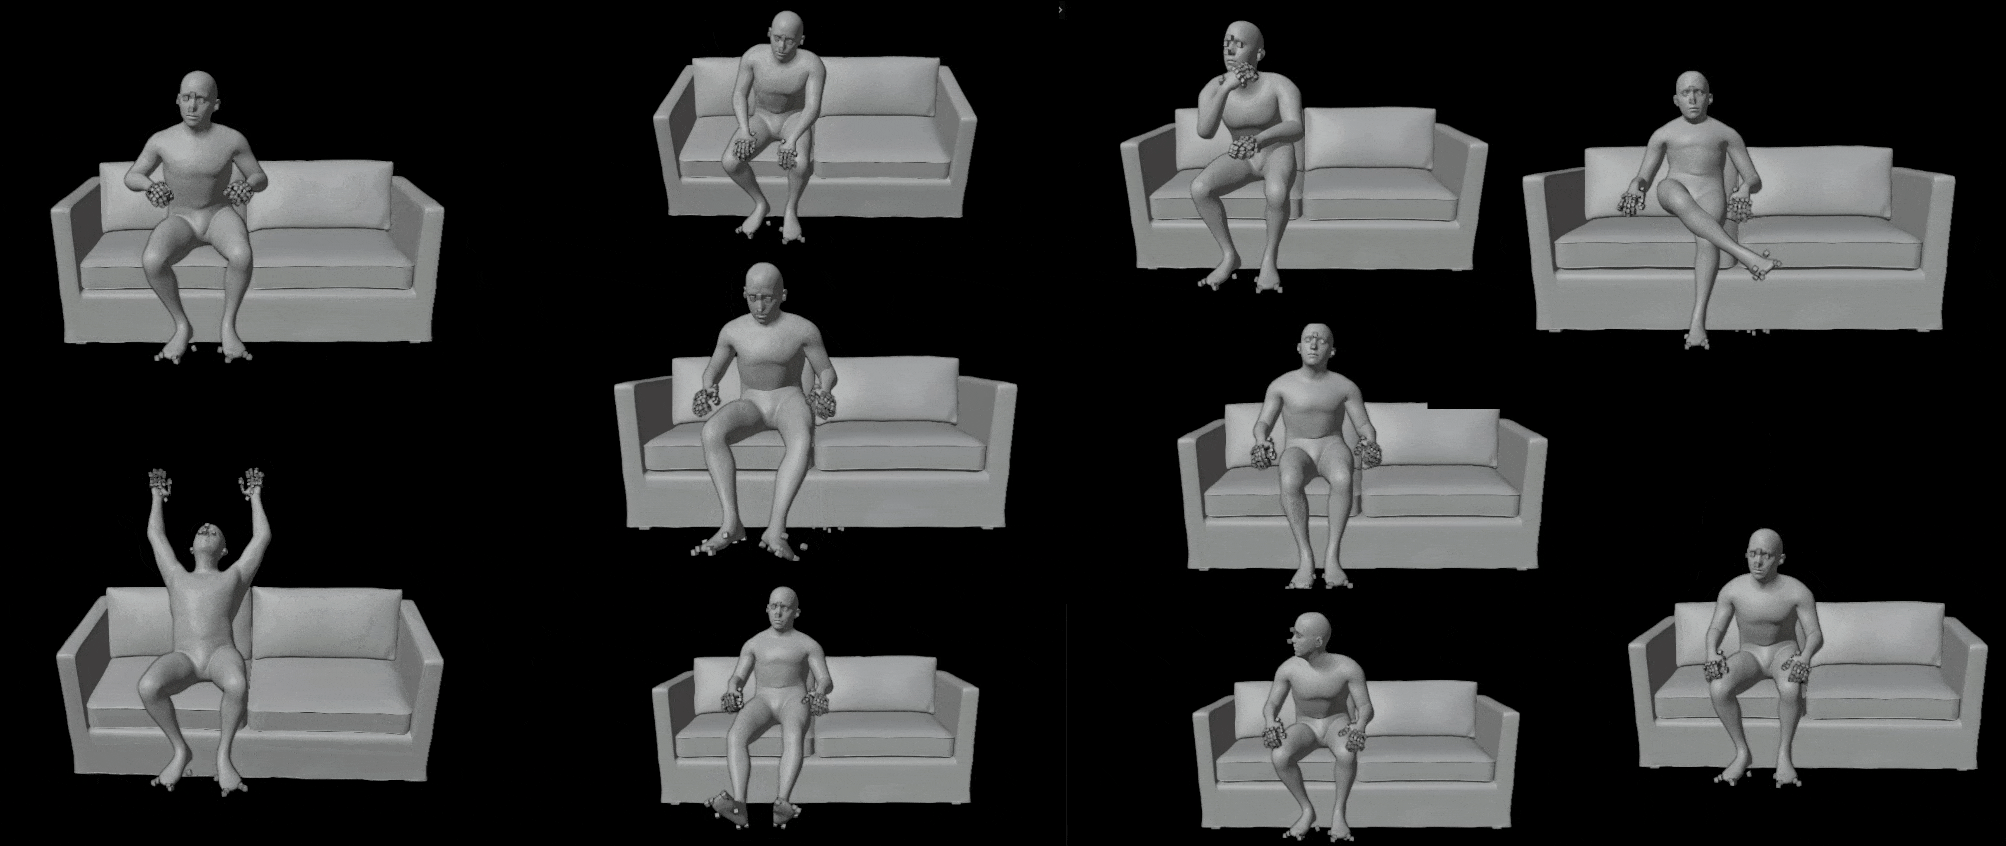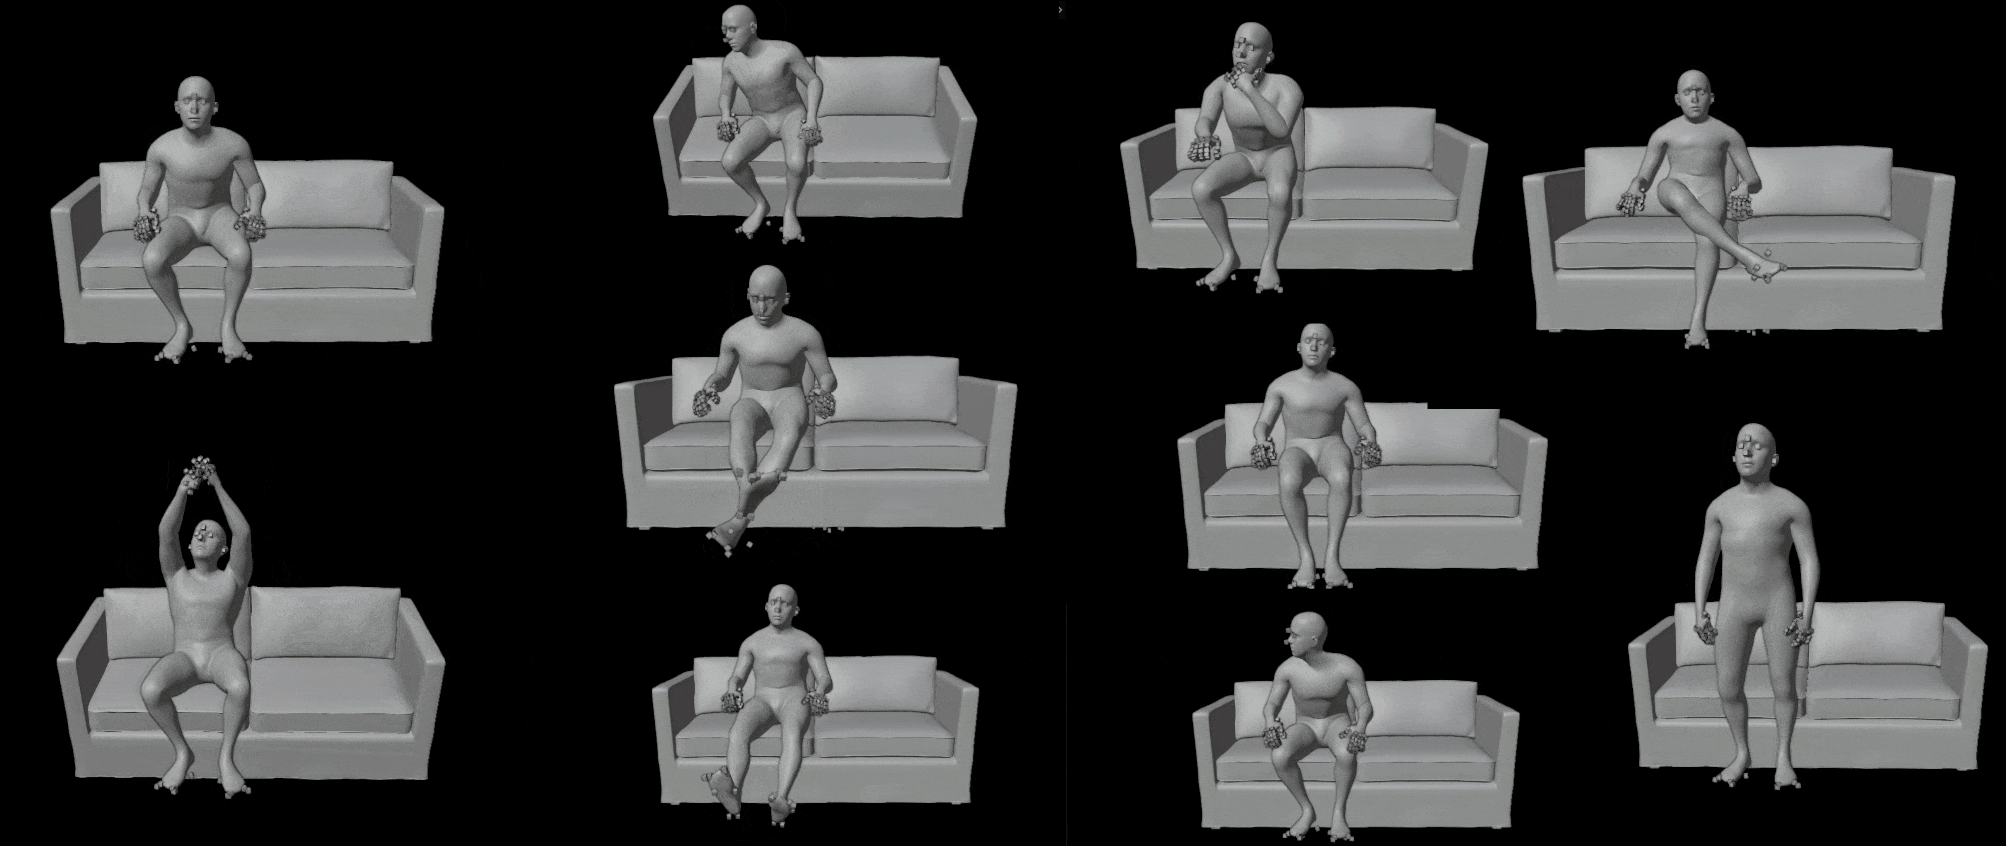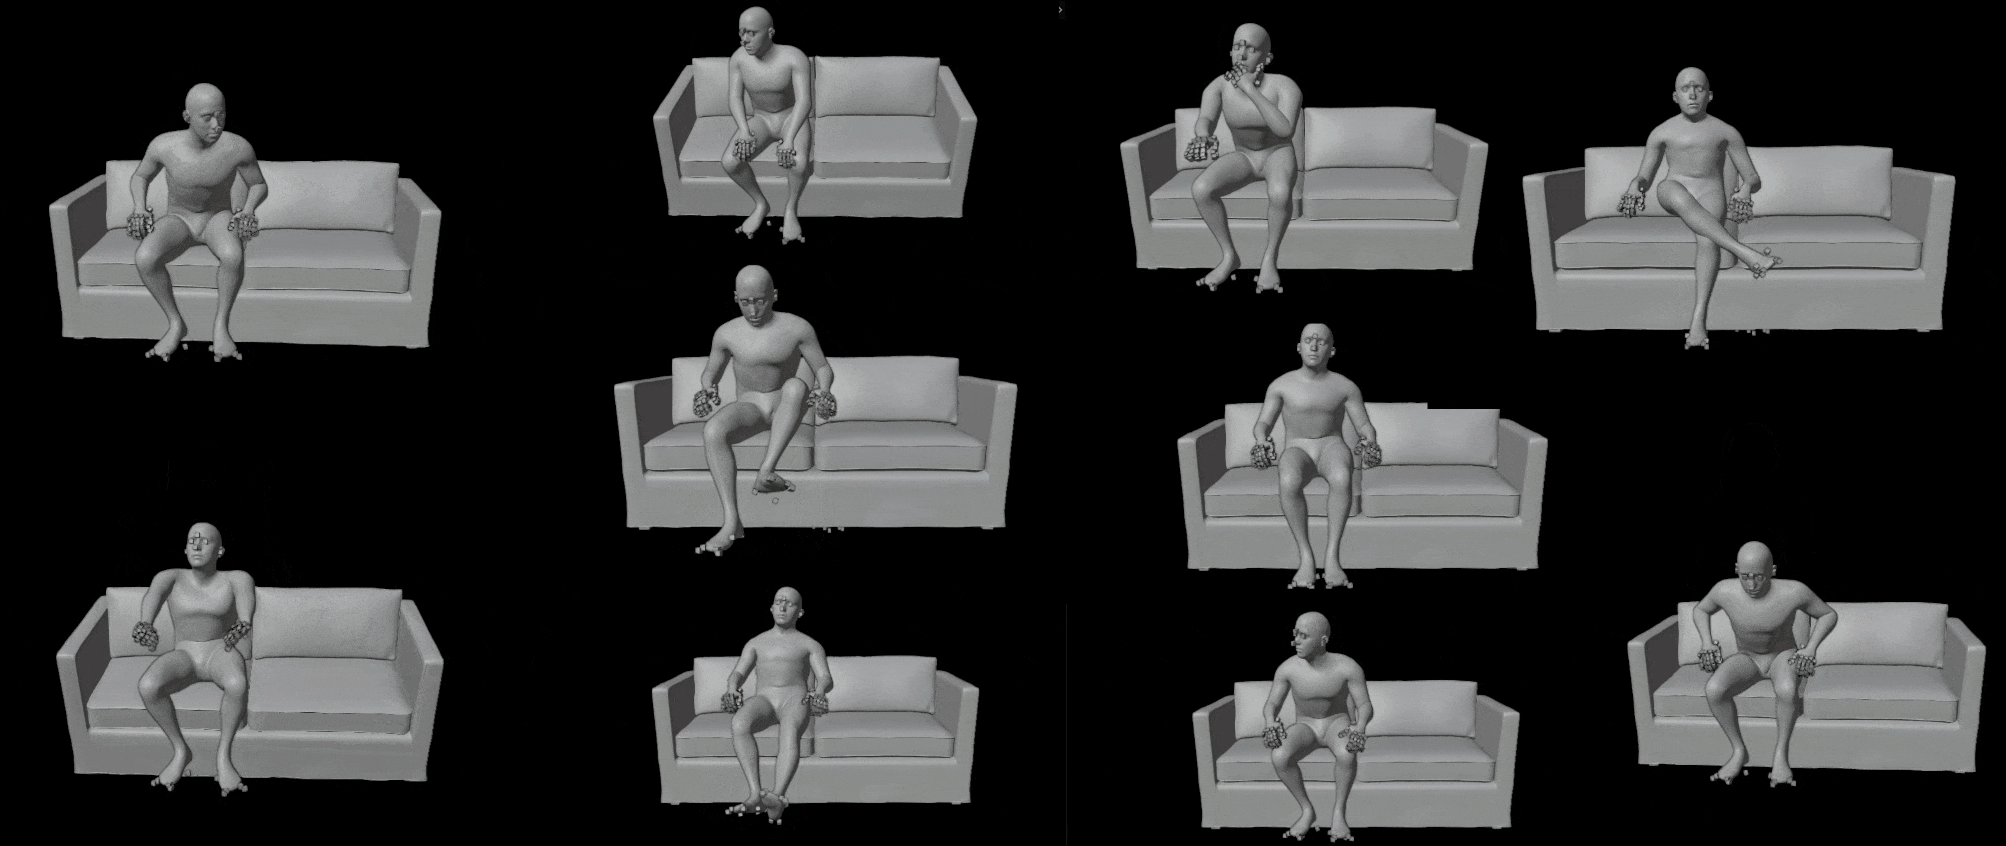
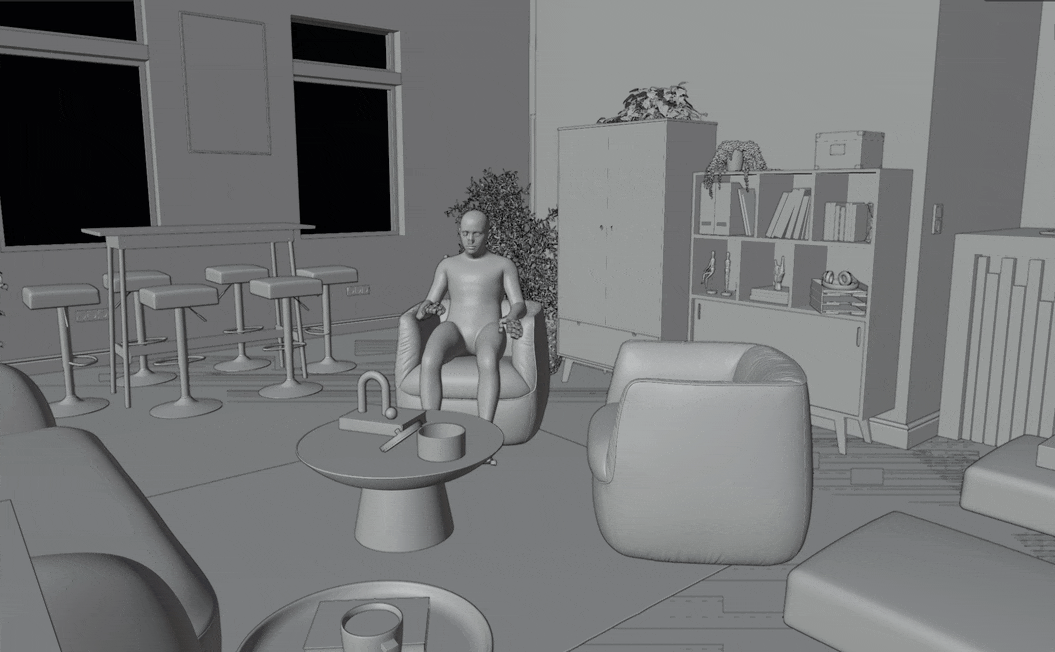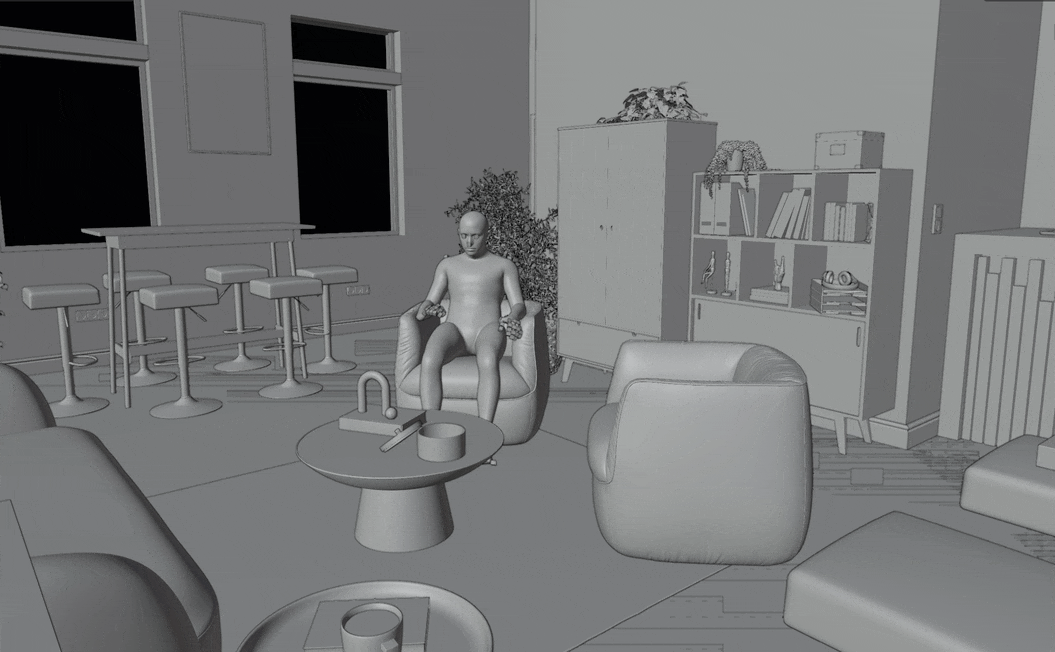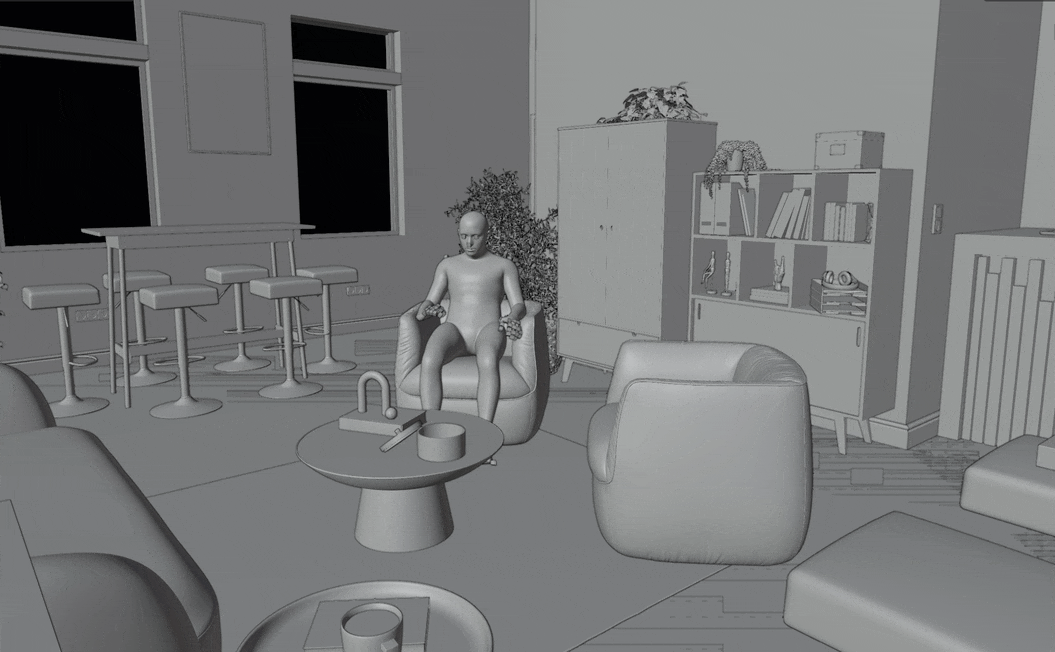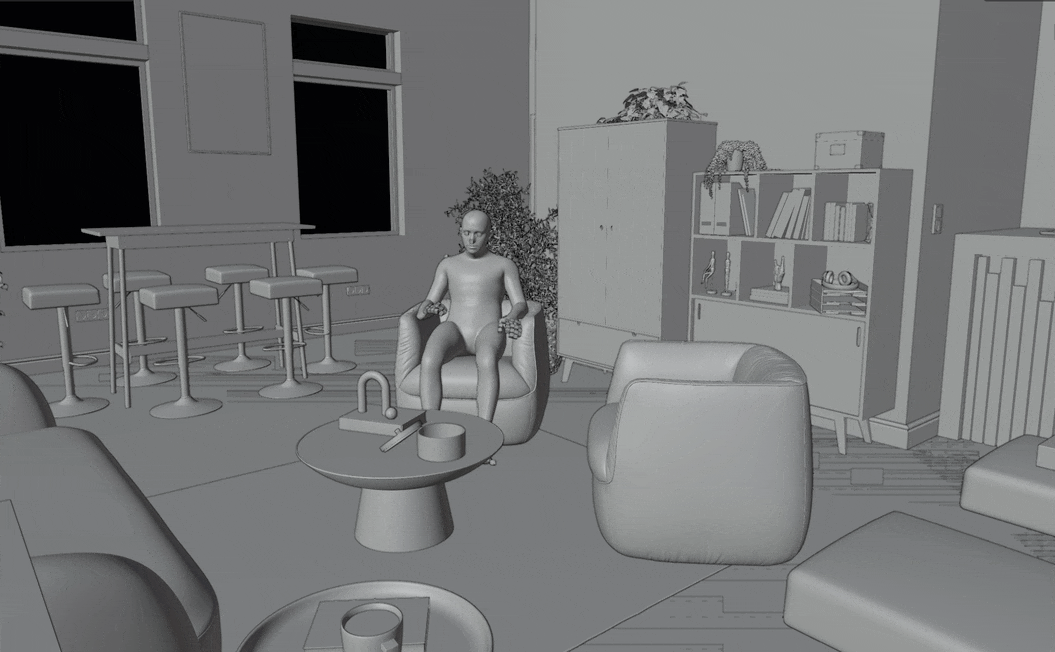
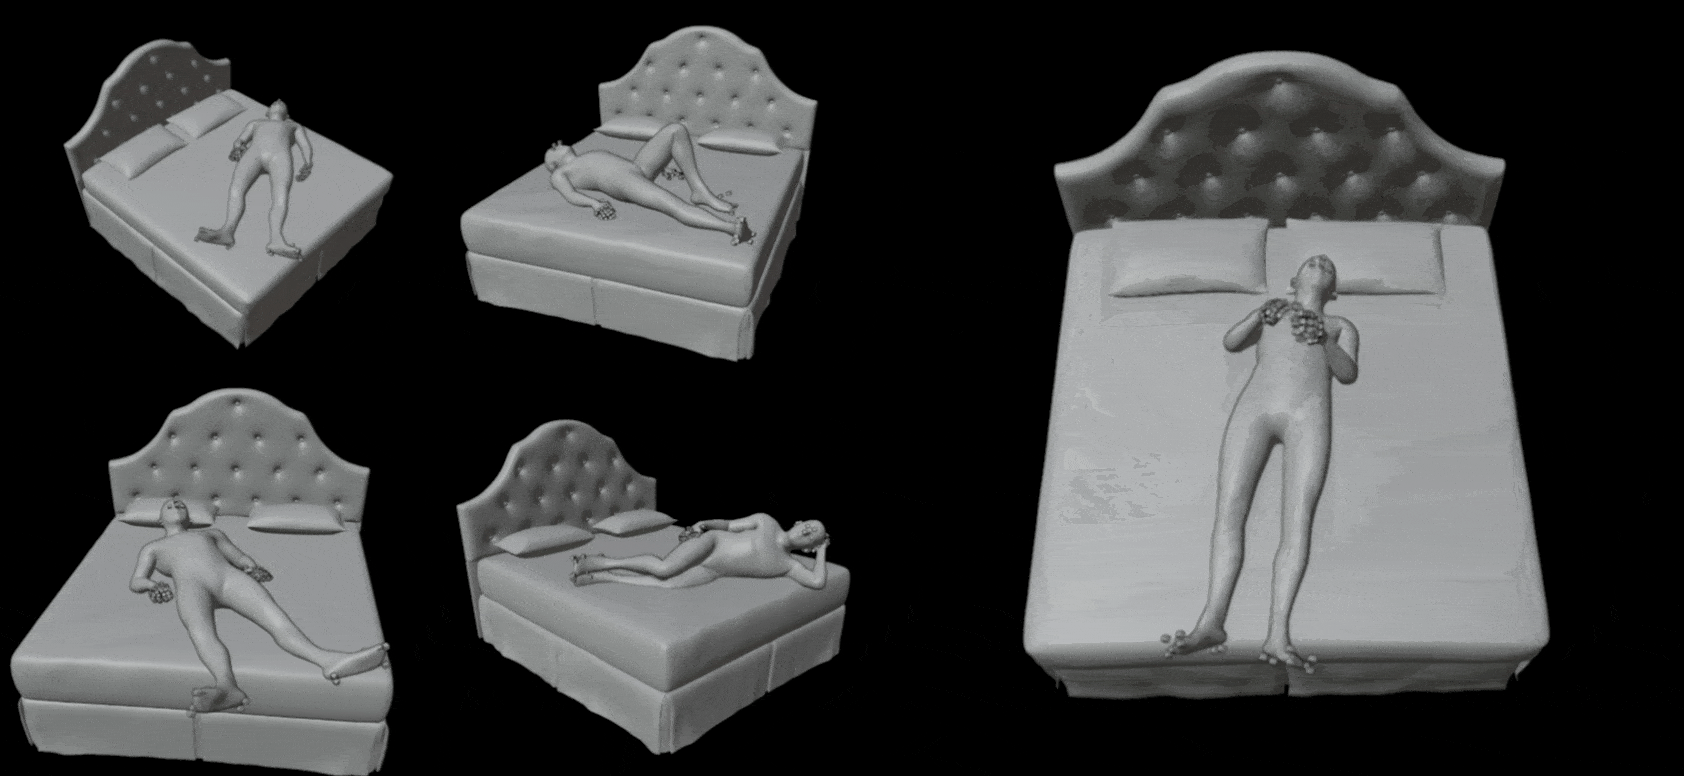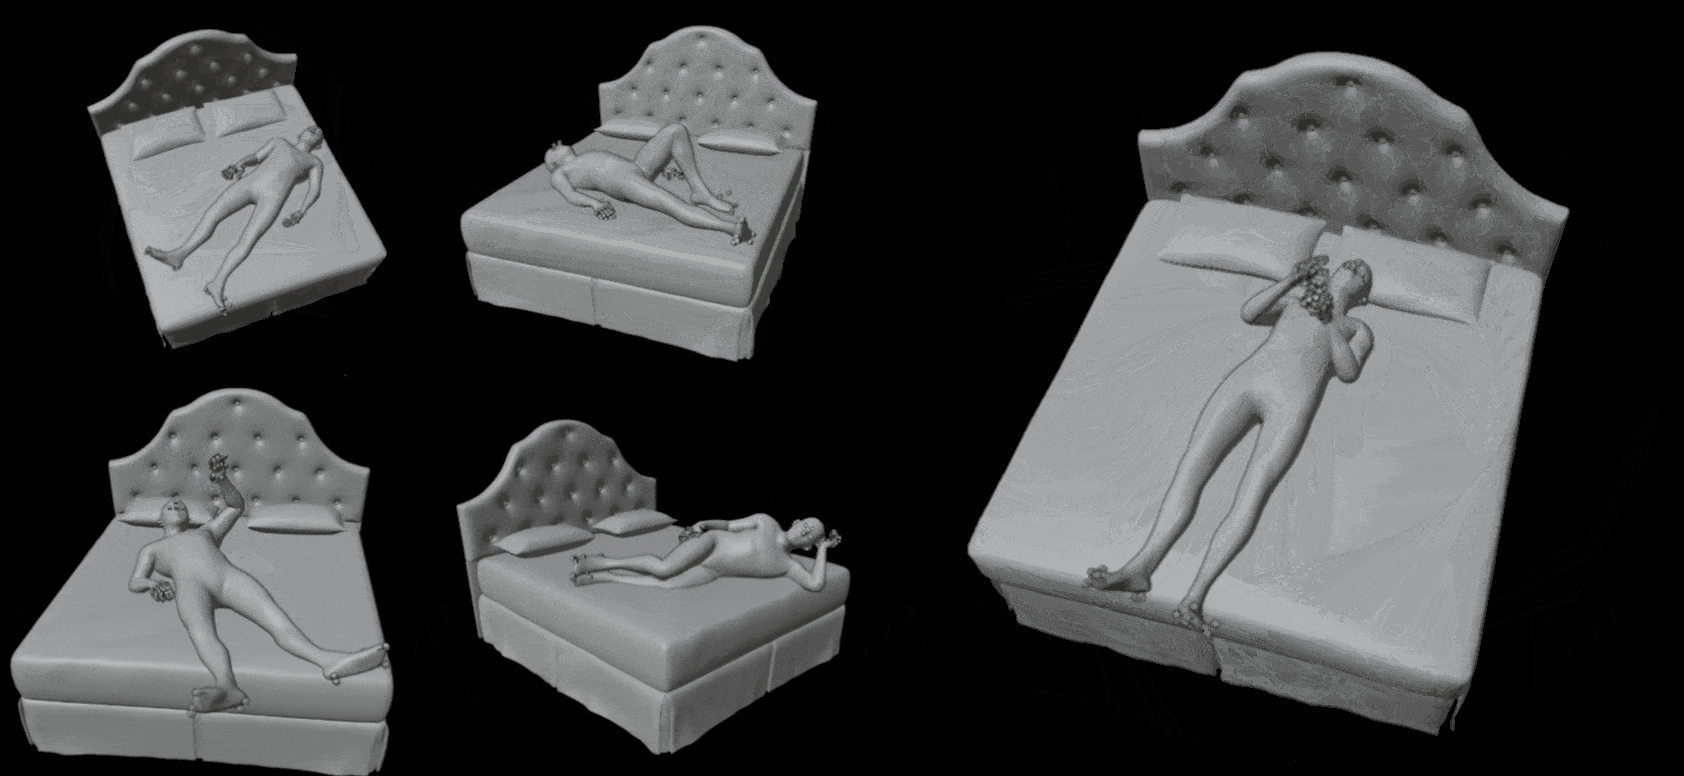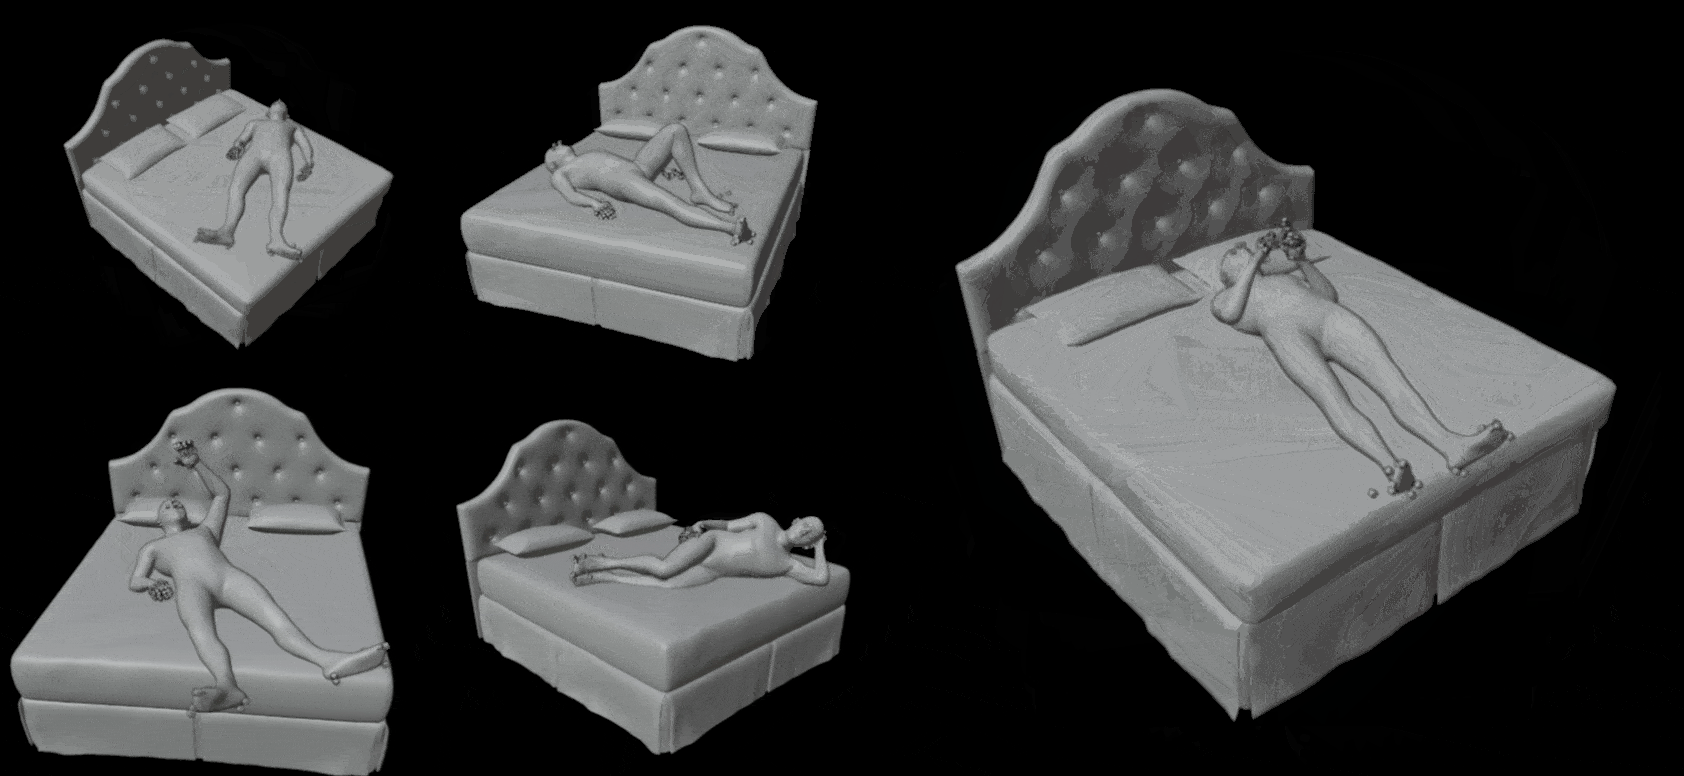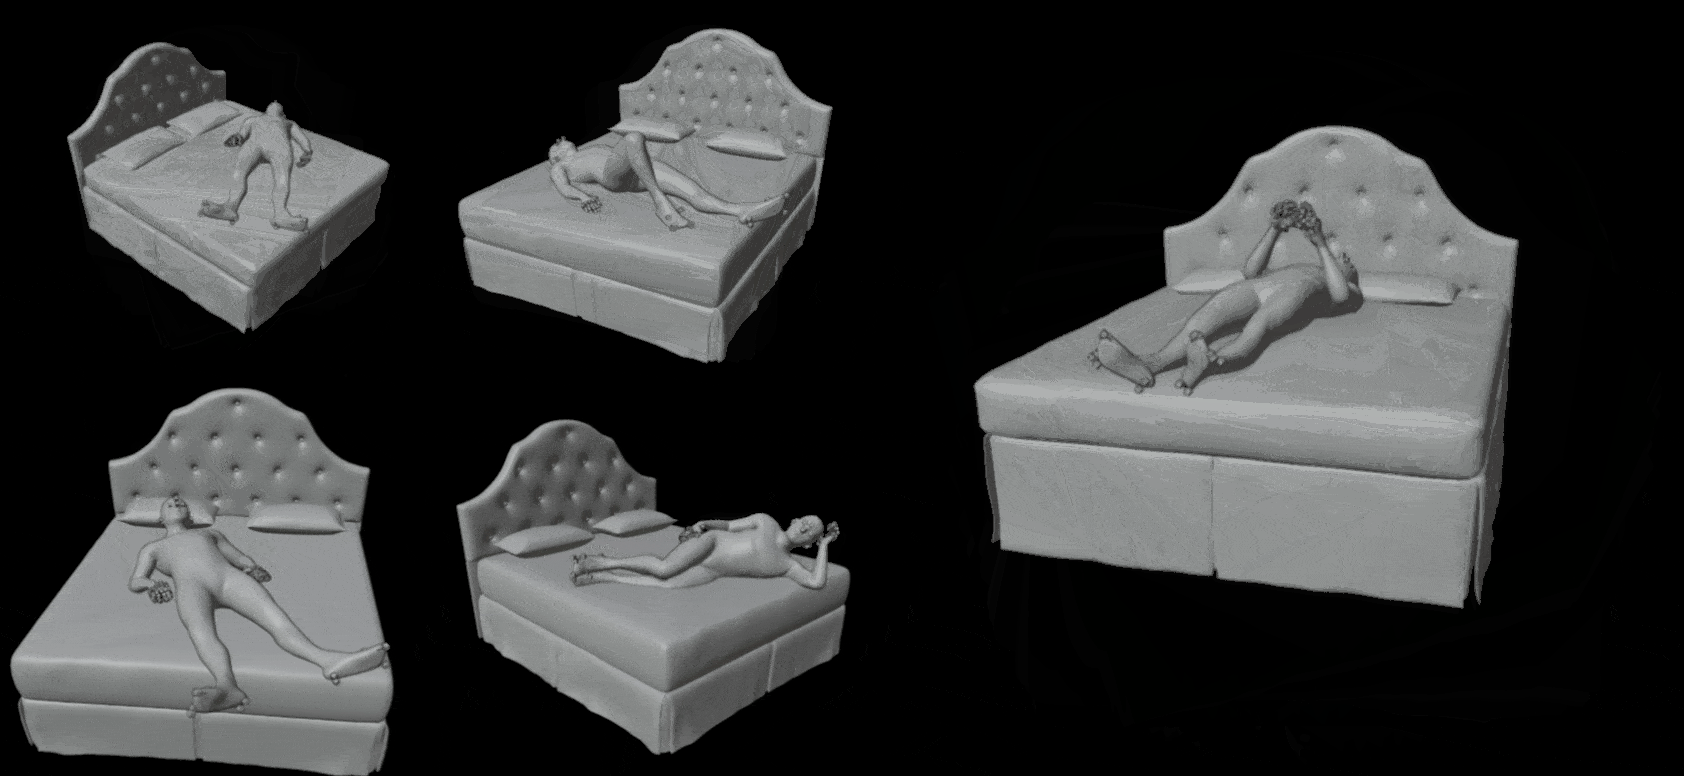
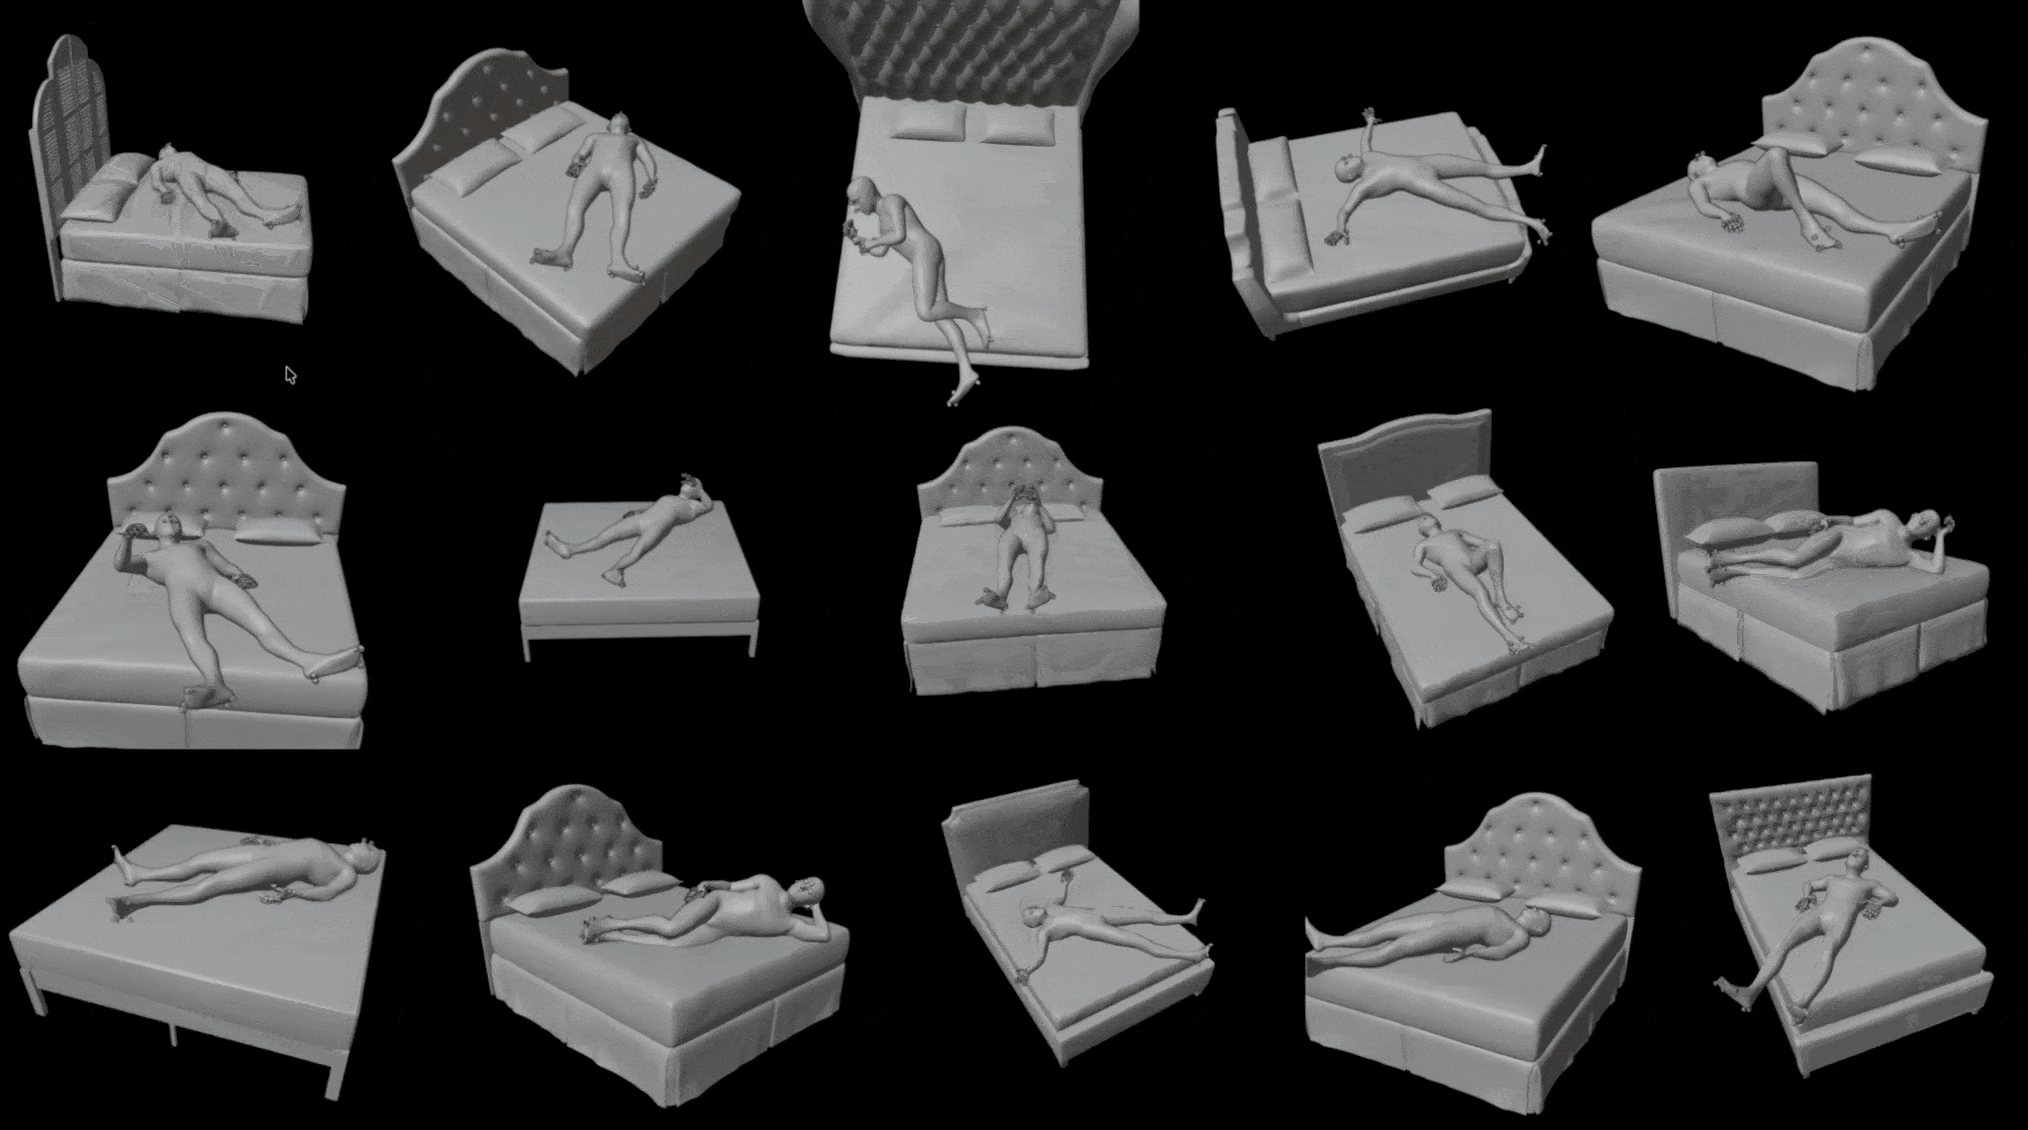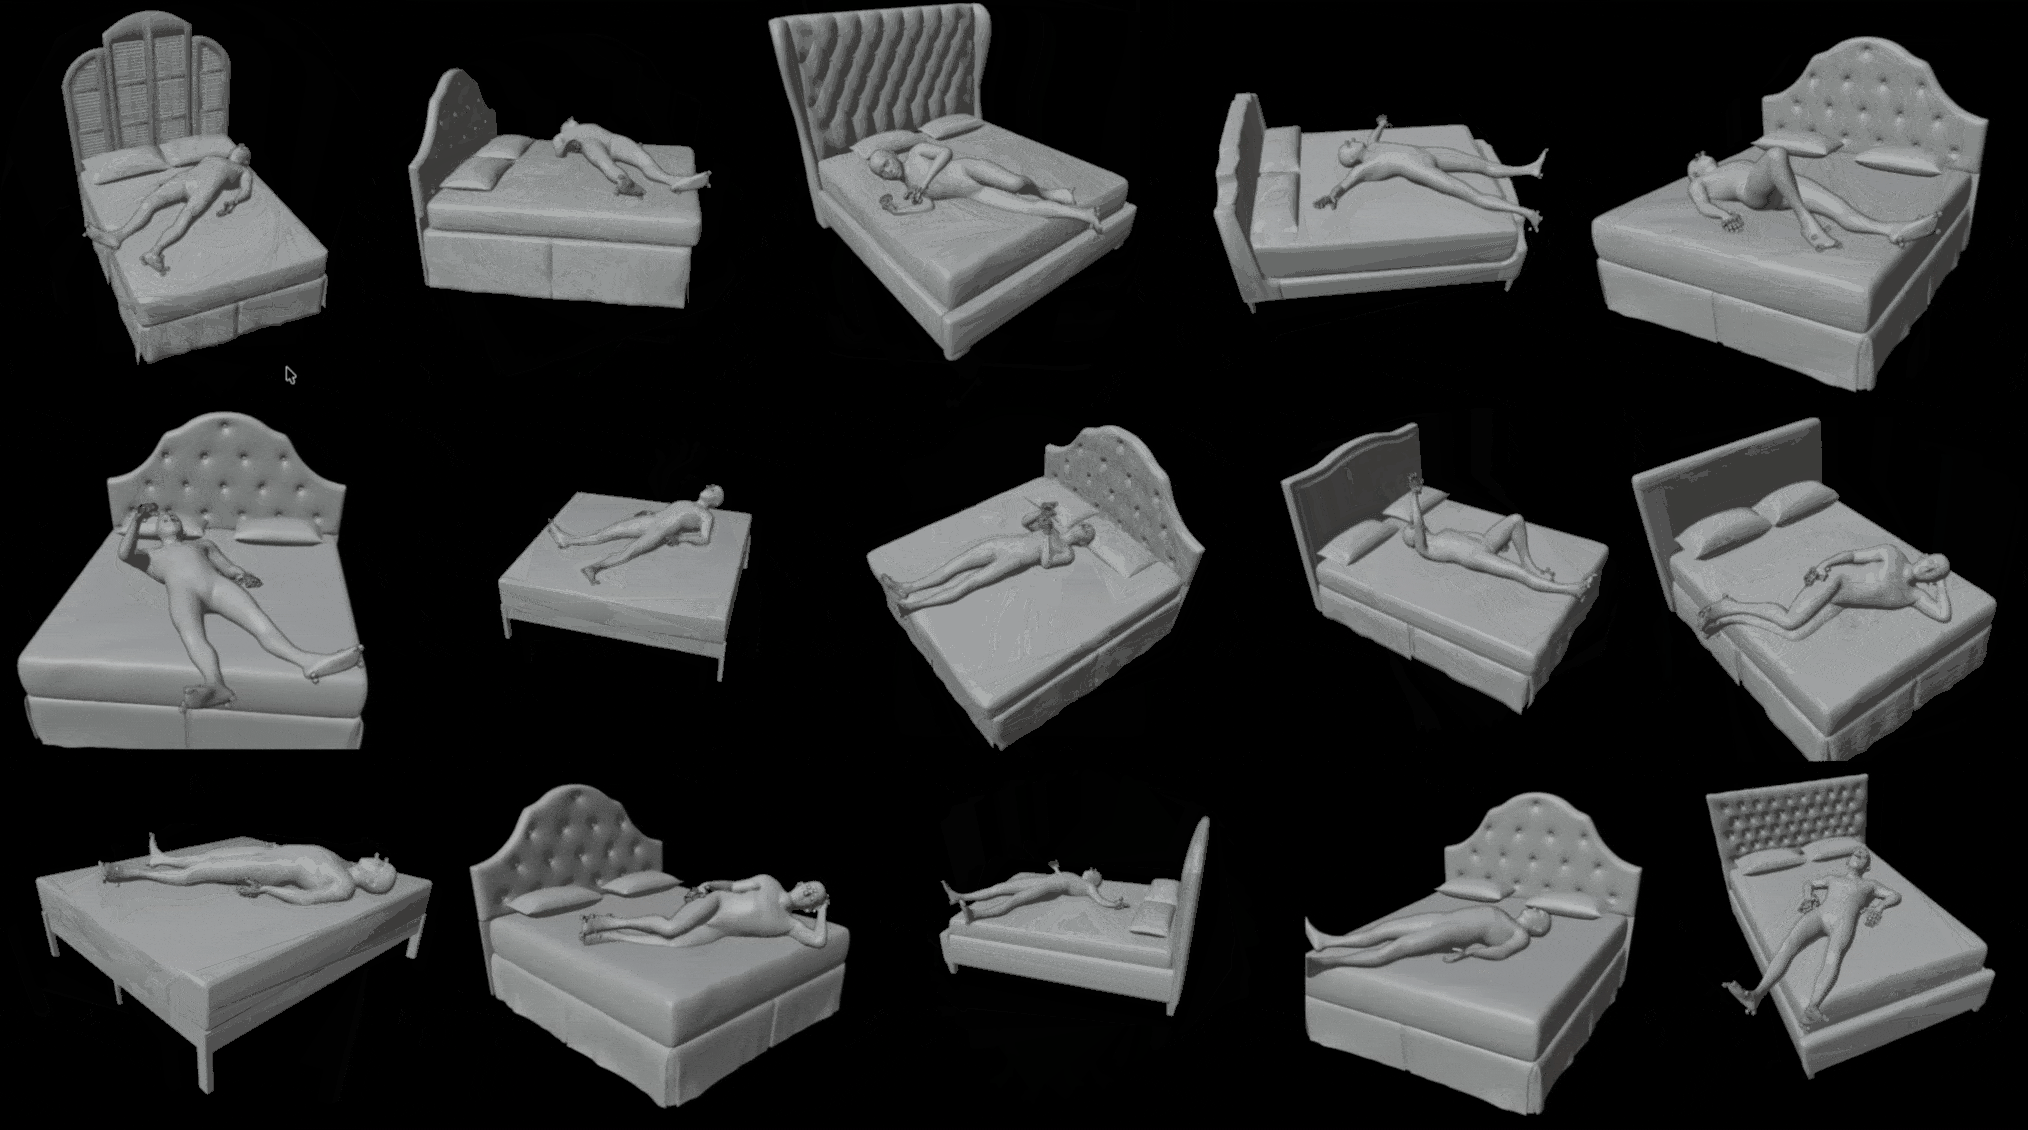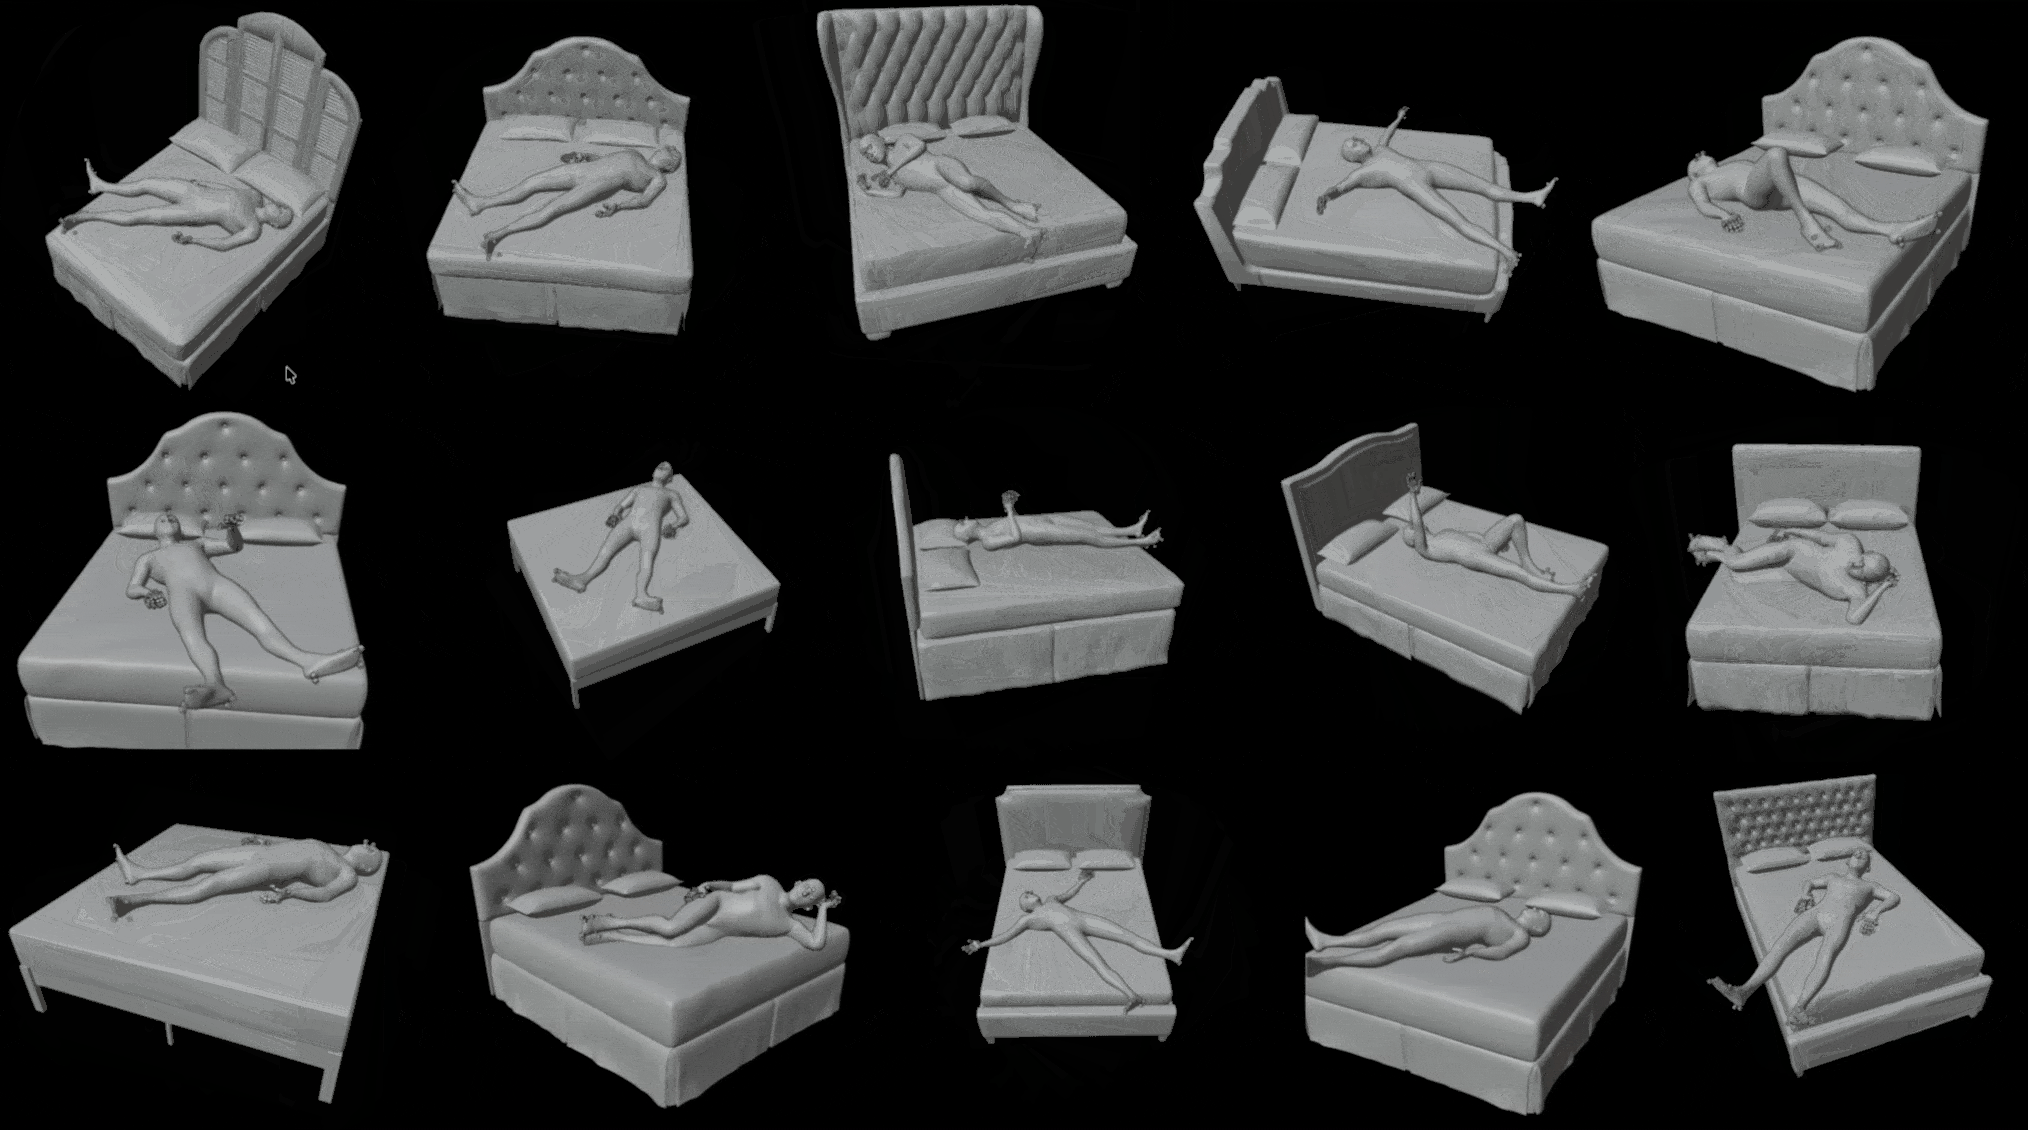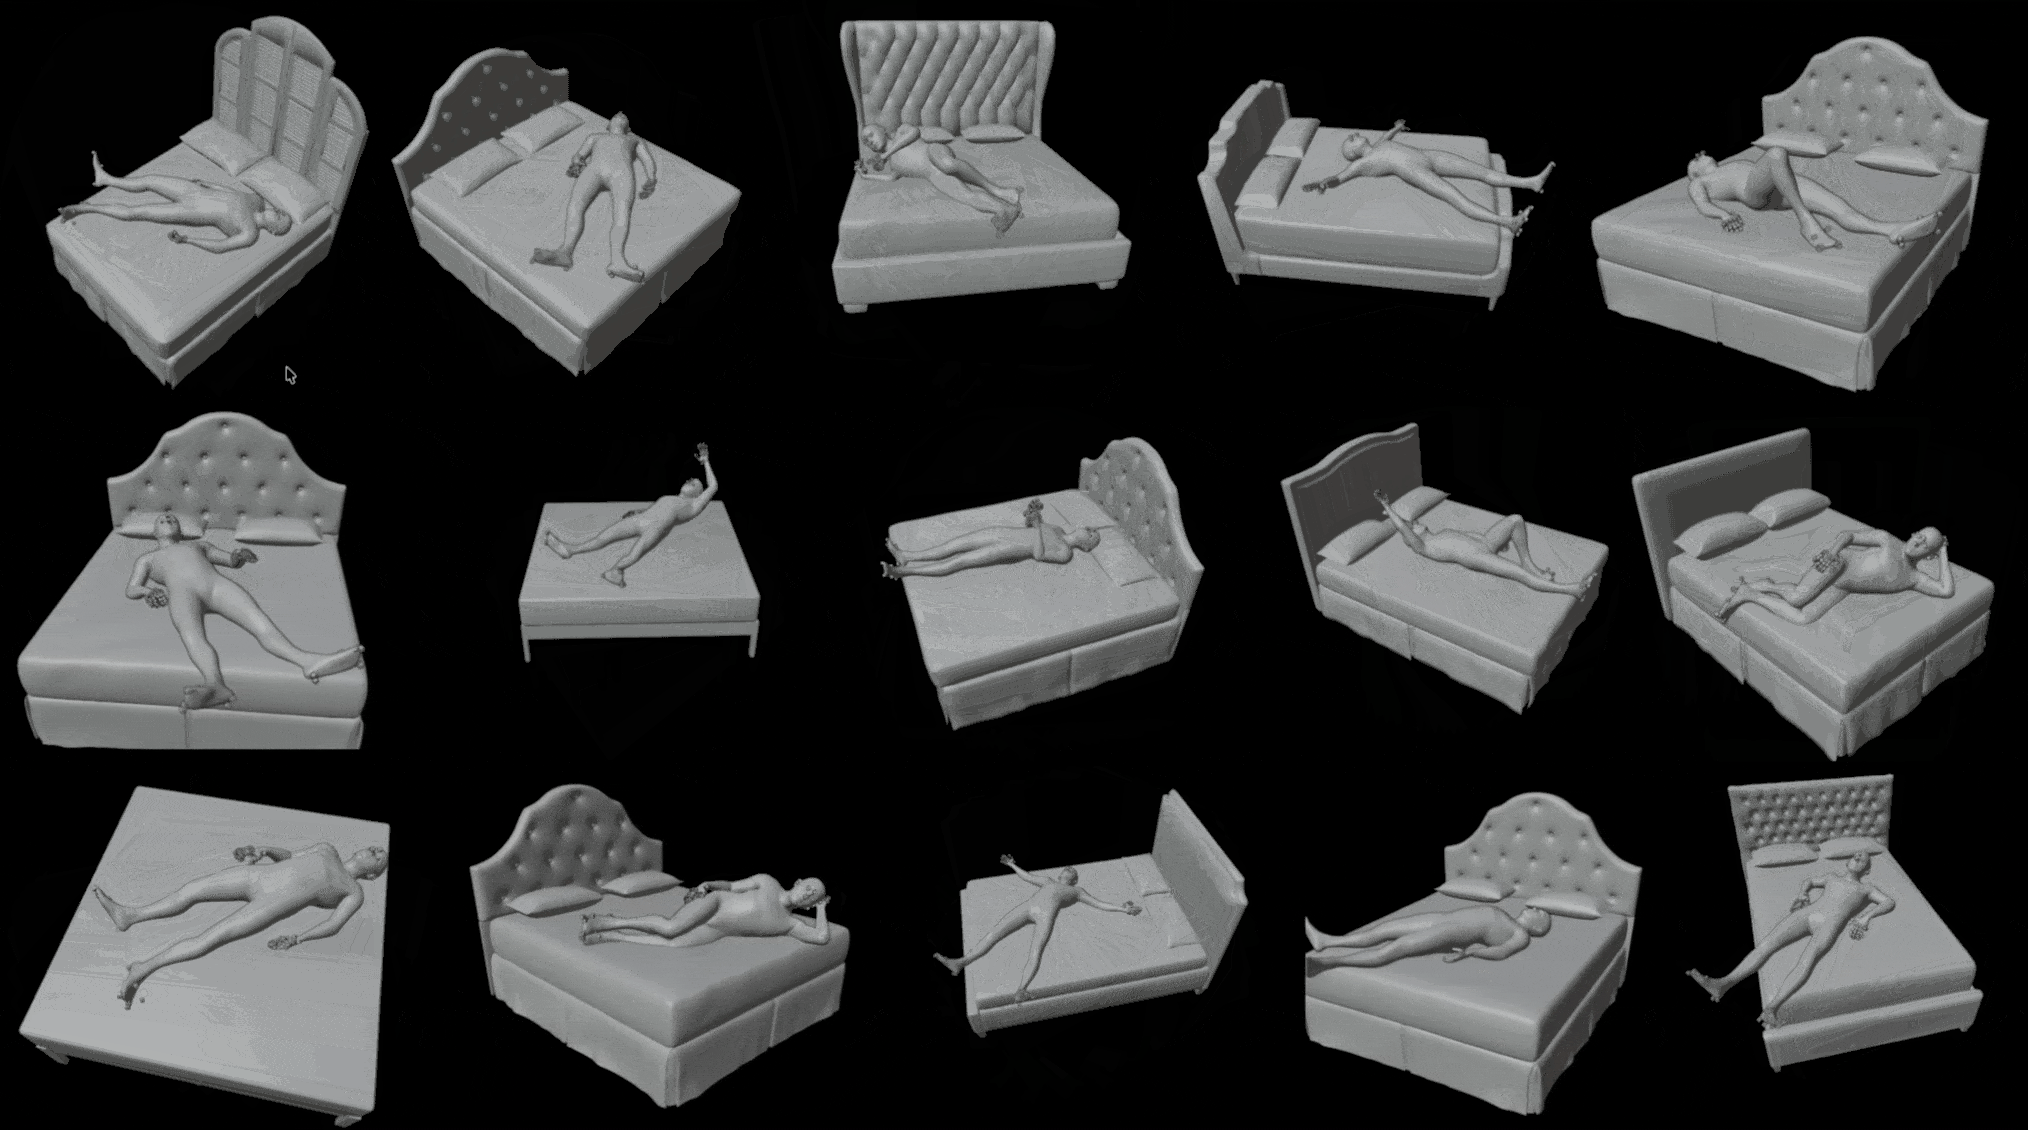
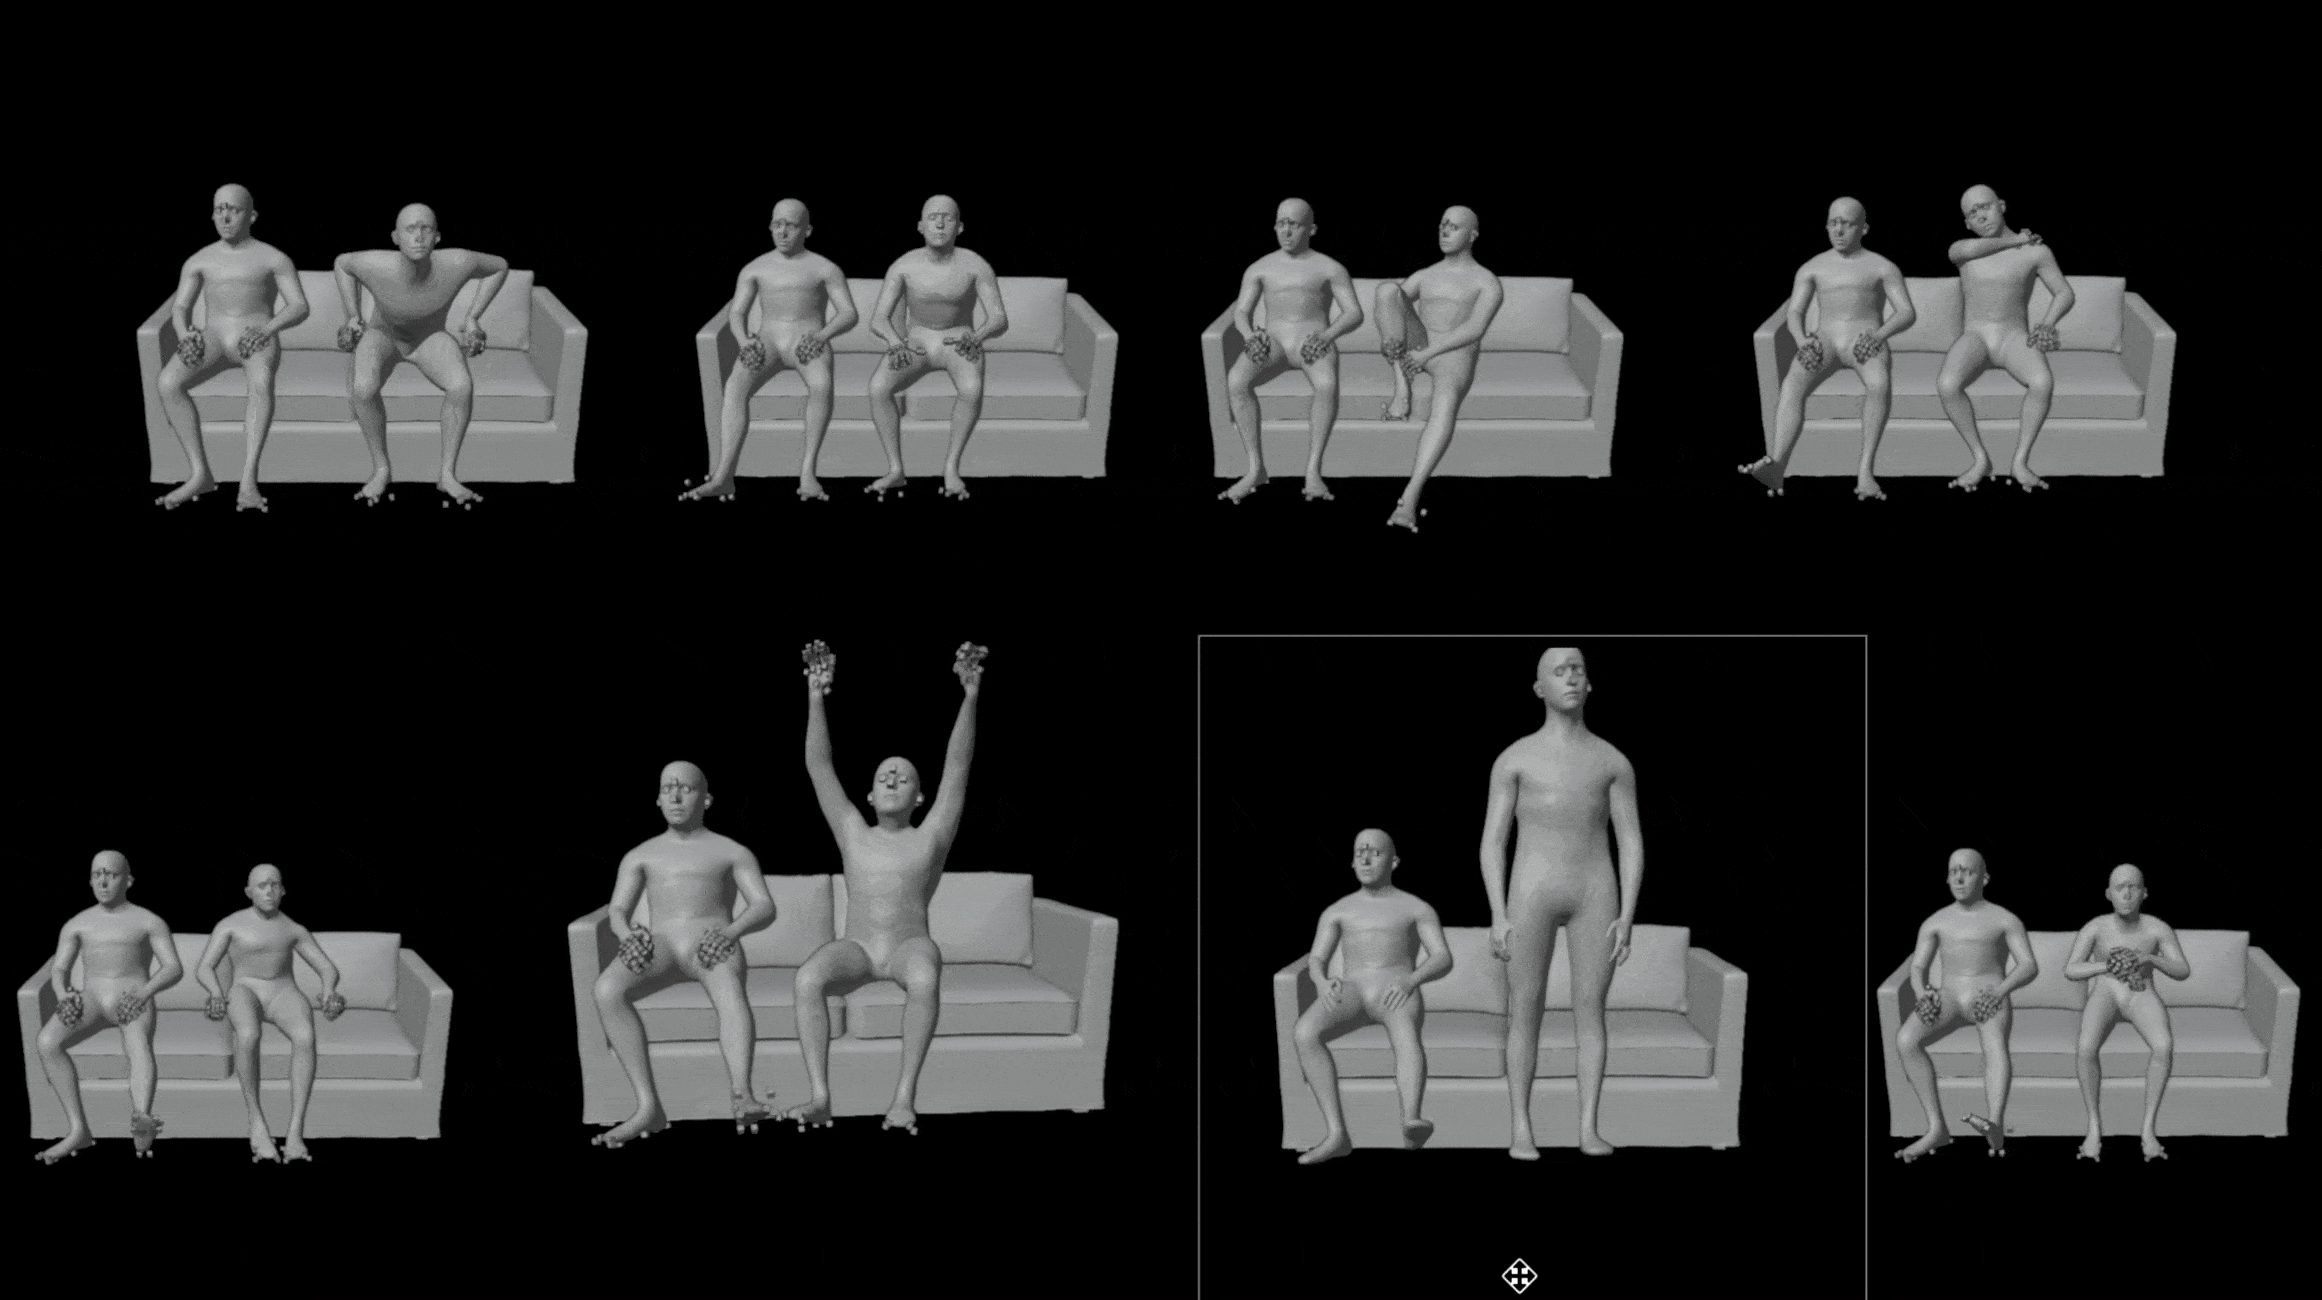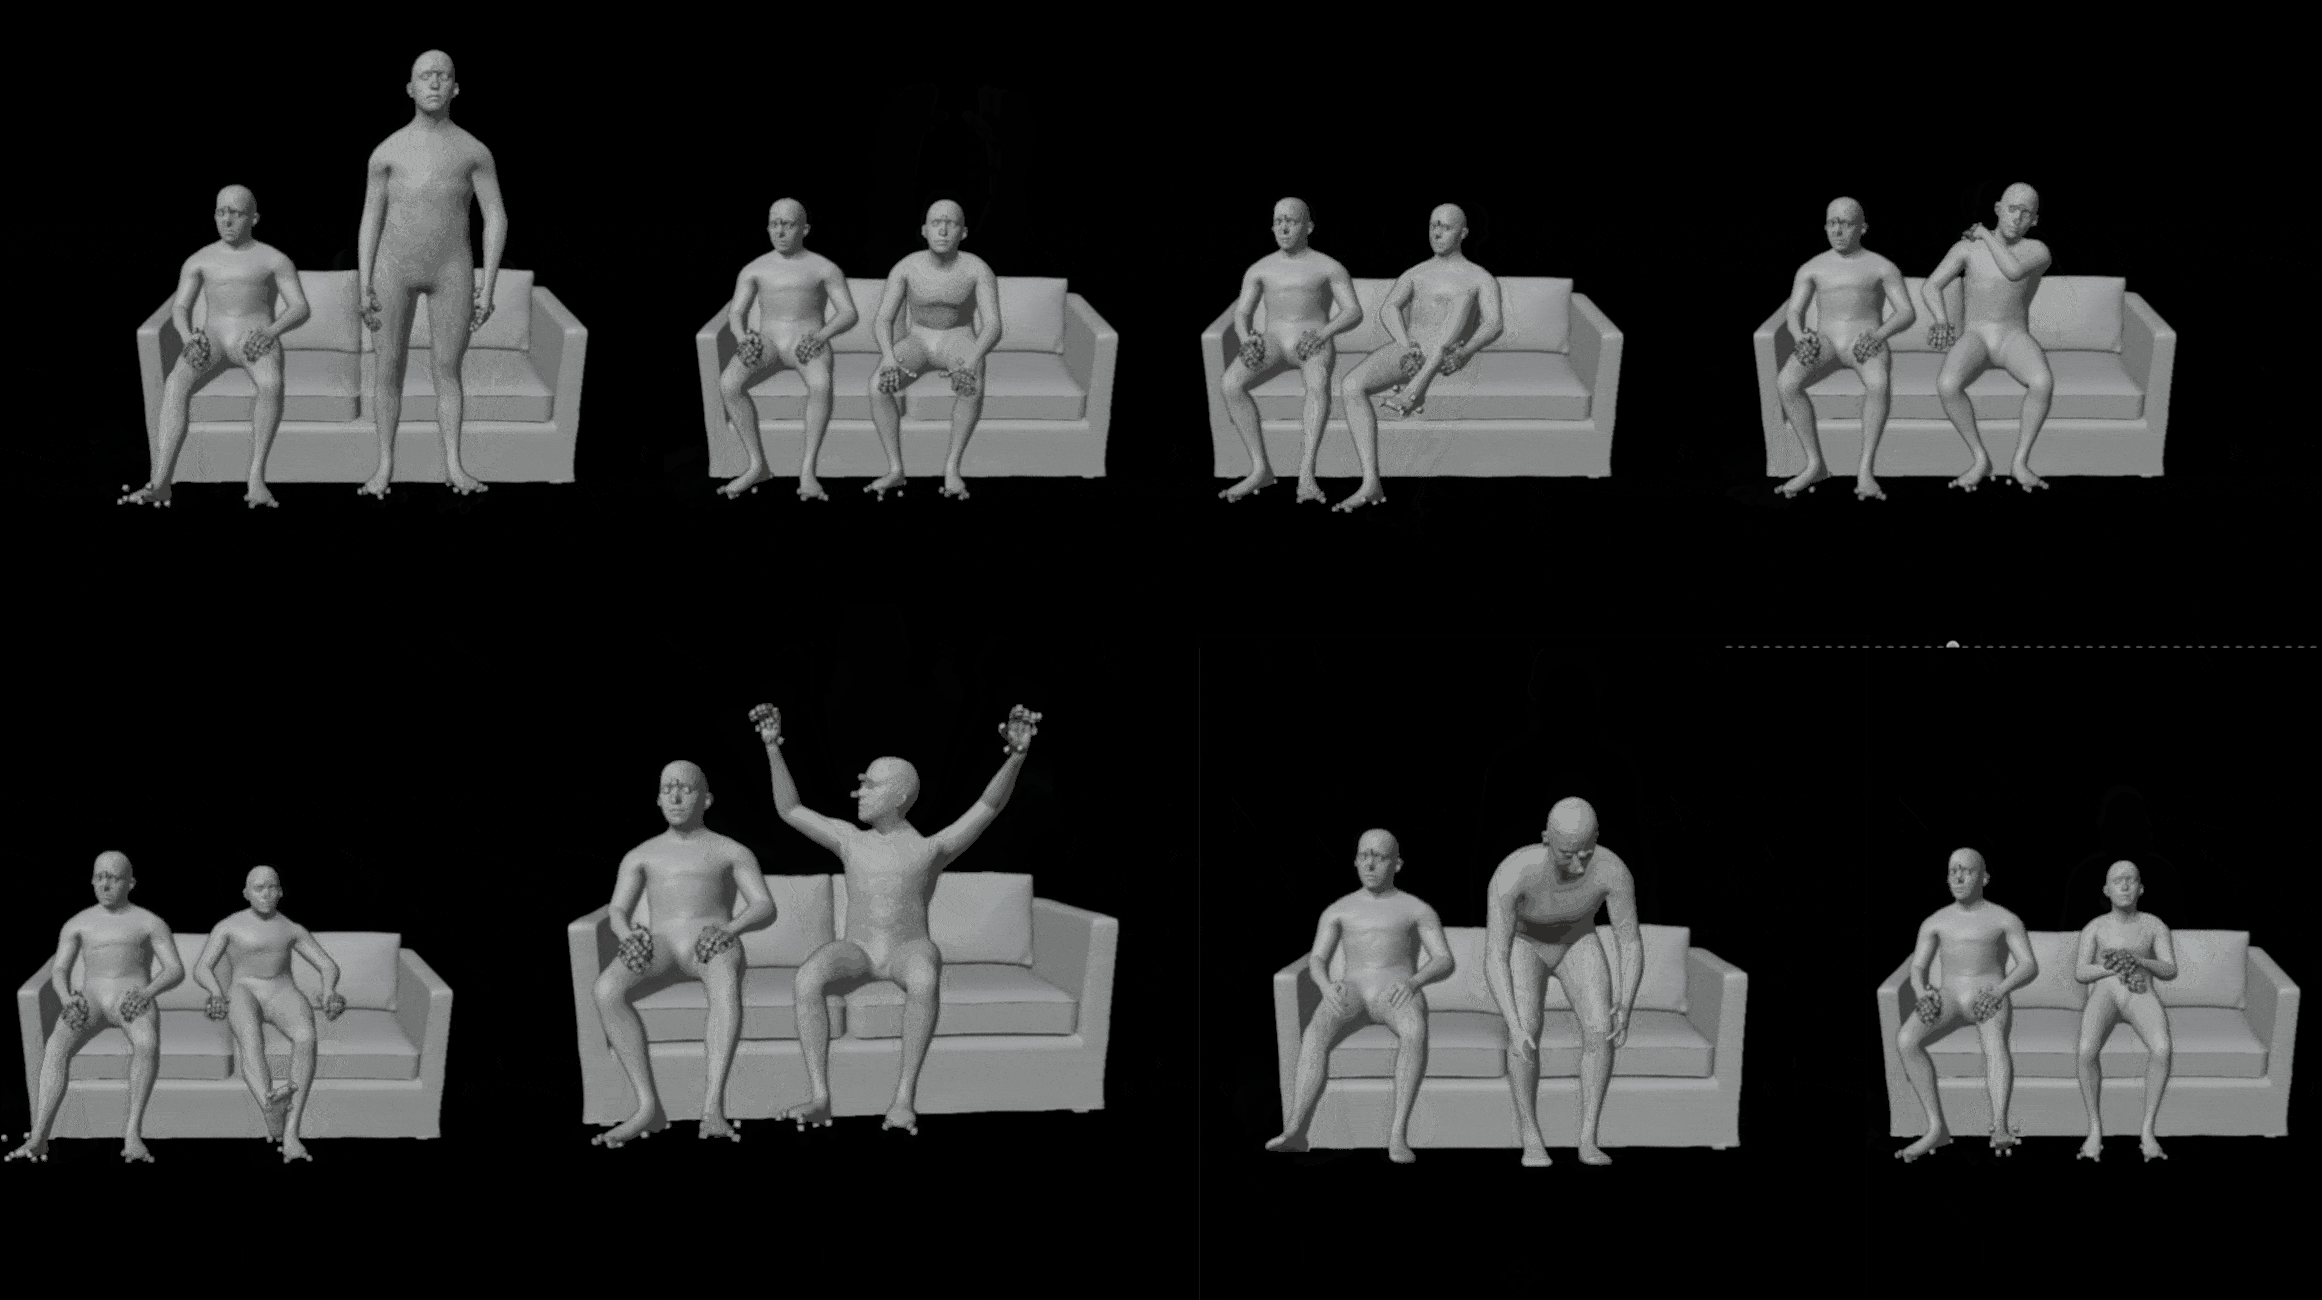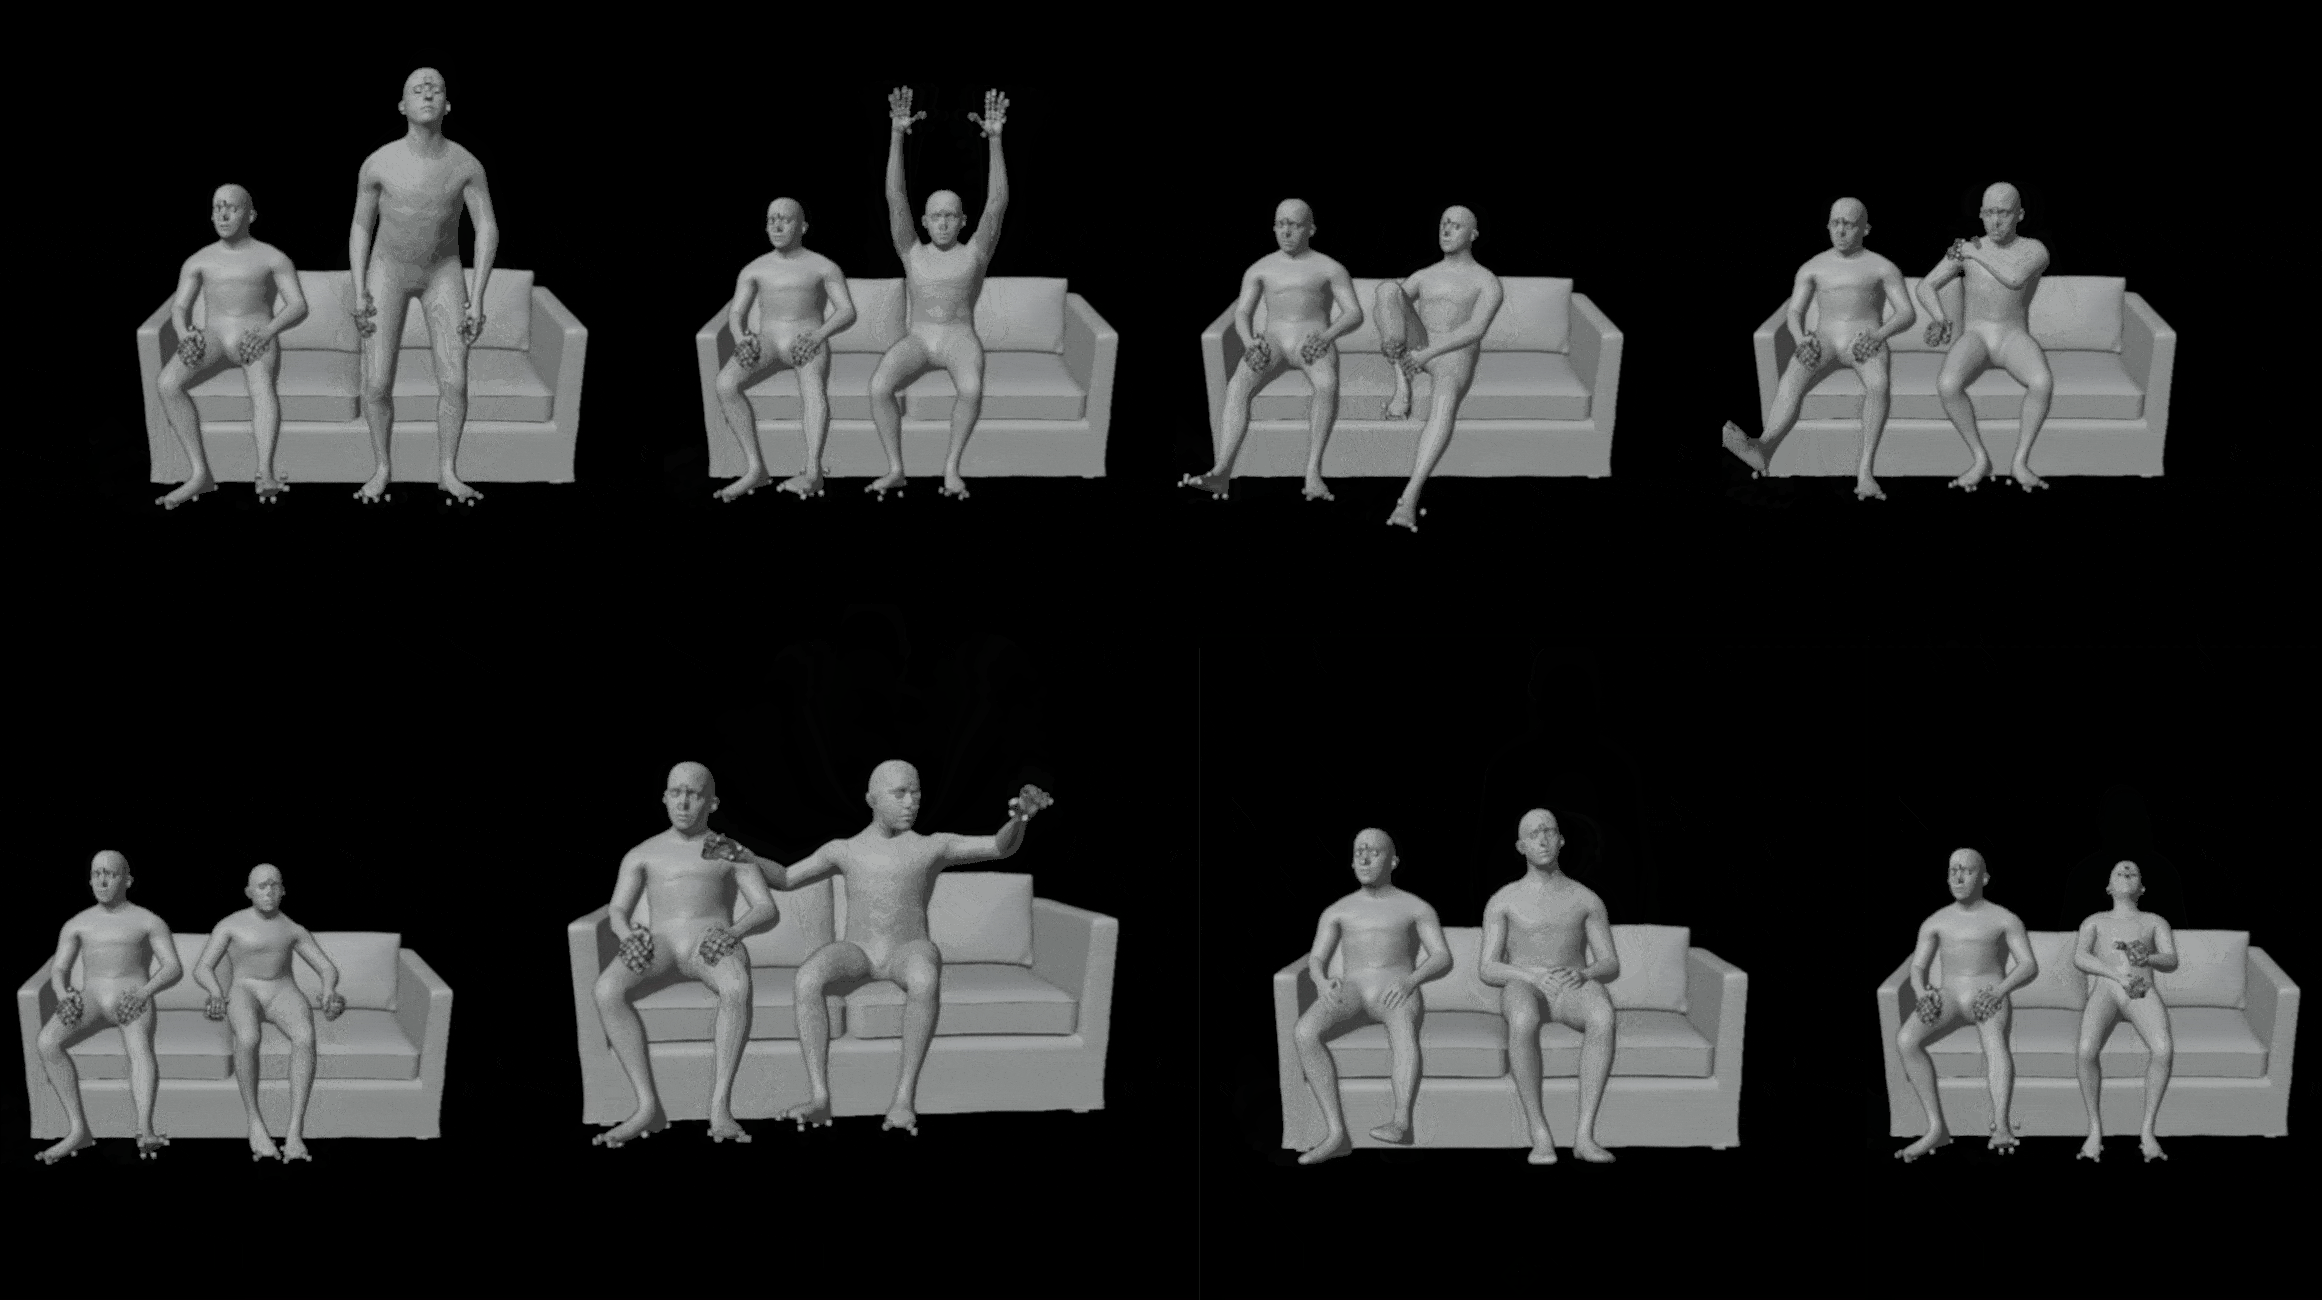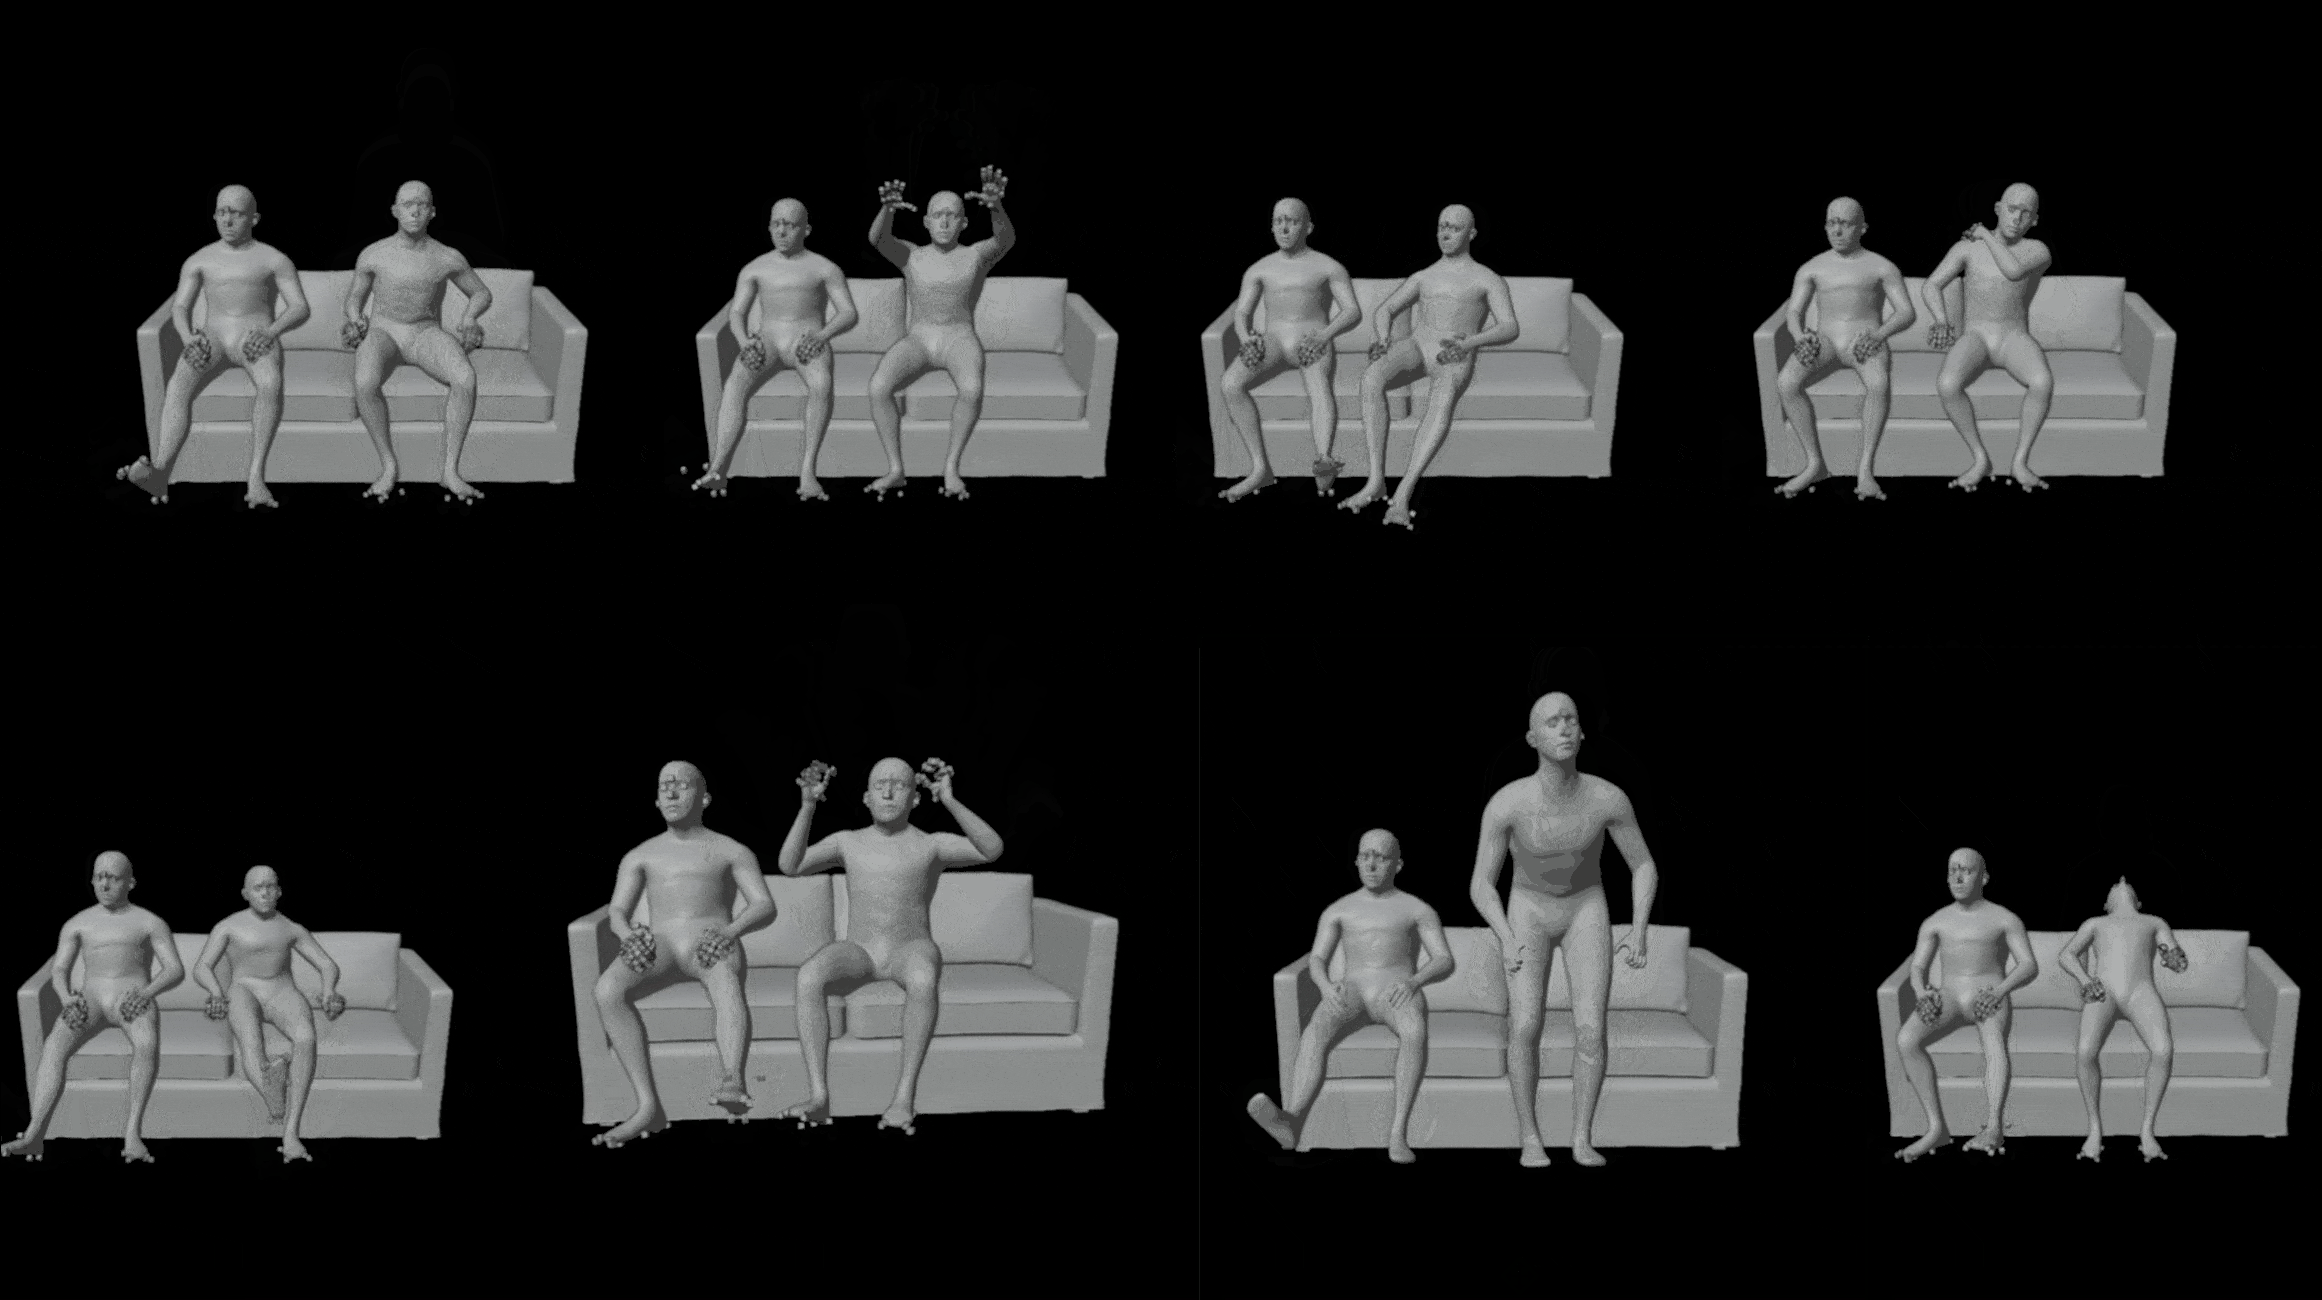
Training robust motion tracking models requires massive datasets of human-object interactions across diverse body shapes, poses, and furniture geometries. Collecting such data in the real world is prohibitively expensive by using motion capture (MoCap) system: each furniture piece must be 3D-scanned, motion capture sessions require significant studio time, and the combinatorial explosion of body shapes, sitting poses, and furniture variations makes exhaustive capture impossible. We present SeatSwap, a differentiable optimization framework that solves this data scarcity problem by automatically adapting a small set of motion-captured sitting animations to arbitrary 3D furniture geometry. Given a captured sitting motion and a target furniture mesh, SeatSwap produces a physically plausible motion sequence of sitting pose where the character maintains proper contact with the seat surface—effectively enabling unlimited permutations of body-furniture combinations from limited source data. Our key technical contribution is a novel biomechanical optimization pipeline that operates directly on skeletal parameters, enabling gradient-based refinement through forward kinematics and linear blend skinning. SeatSwap retargets existing motion-captured animations while preserving their natural motion characteristics. We integrate neural signed distance fields for differentiable intersection computation and extend the system to support multi-person scenarios through sequential optimization with person-to-person collision avoidance, as well as lying down poses for bed and lounge furniture. Our system processes thousands of furniture pieces in parallel via a distributed job orchestration system, generating the diverse synthetic training data needed to train motion tracking models at Meta scale.
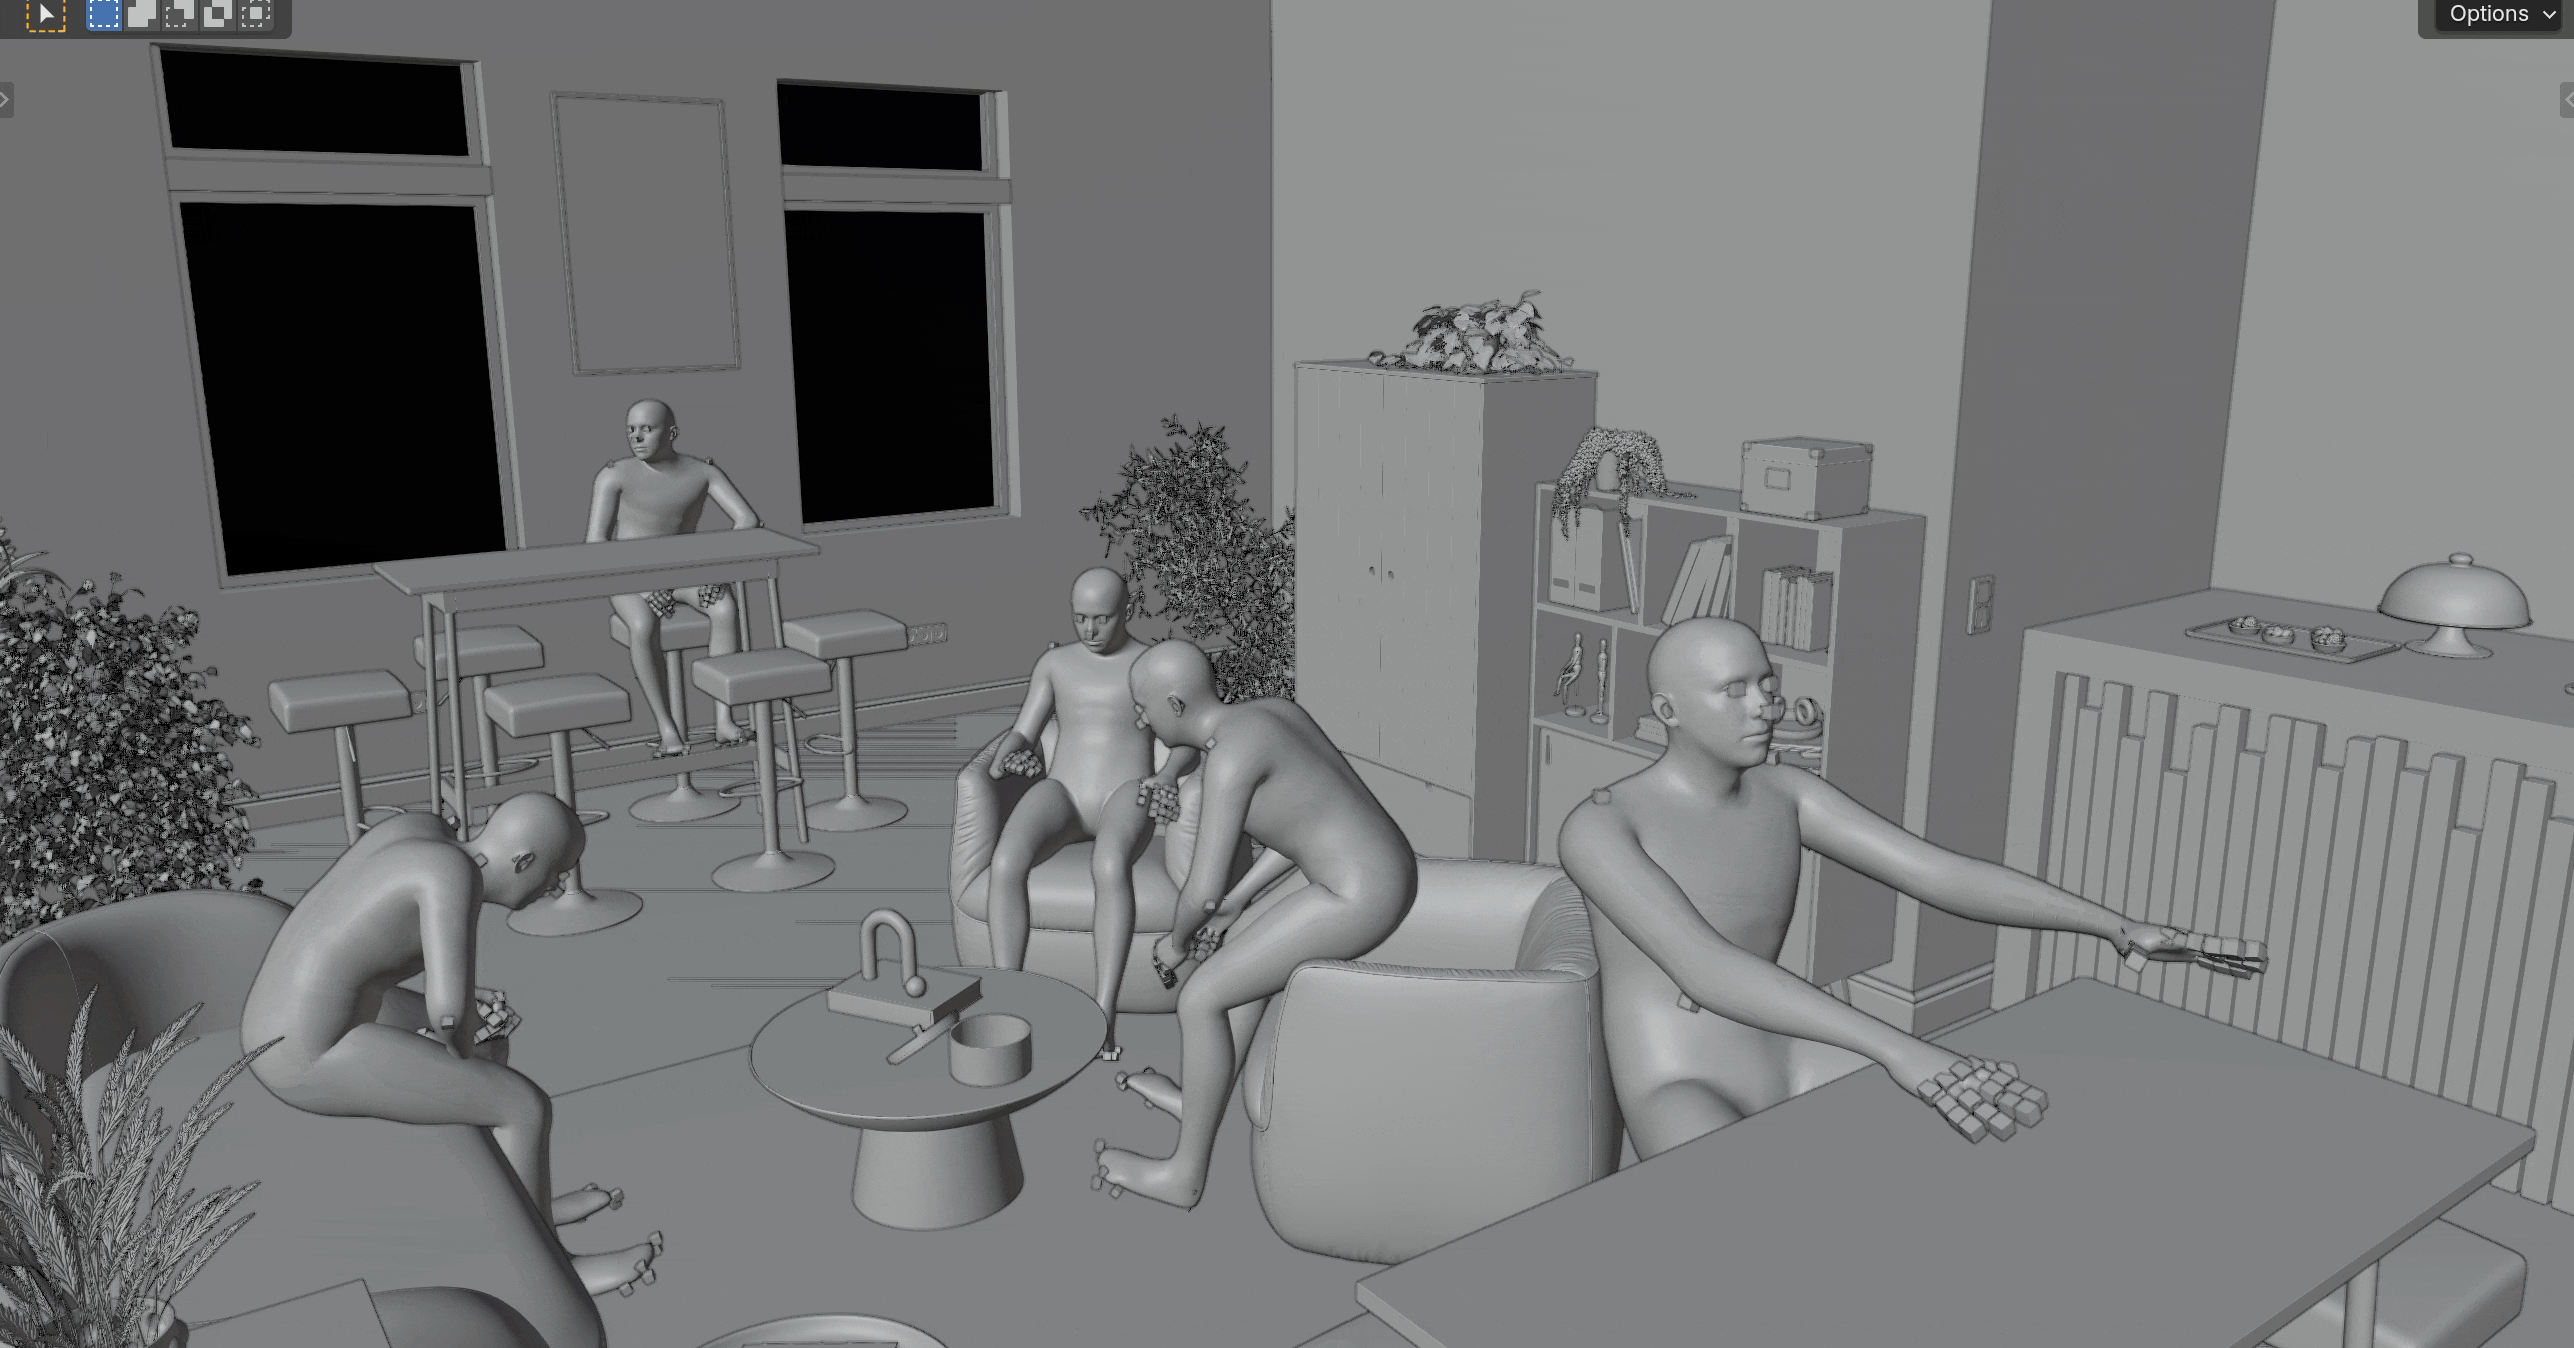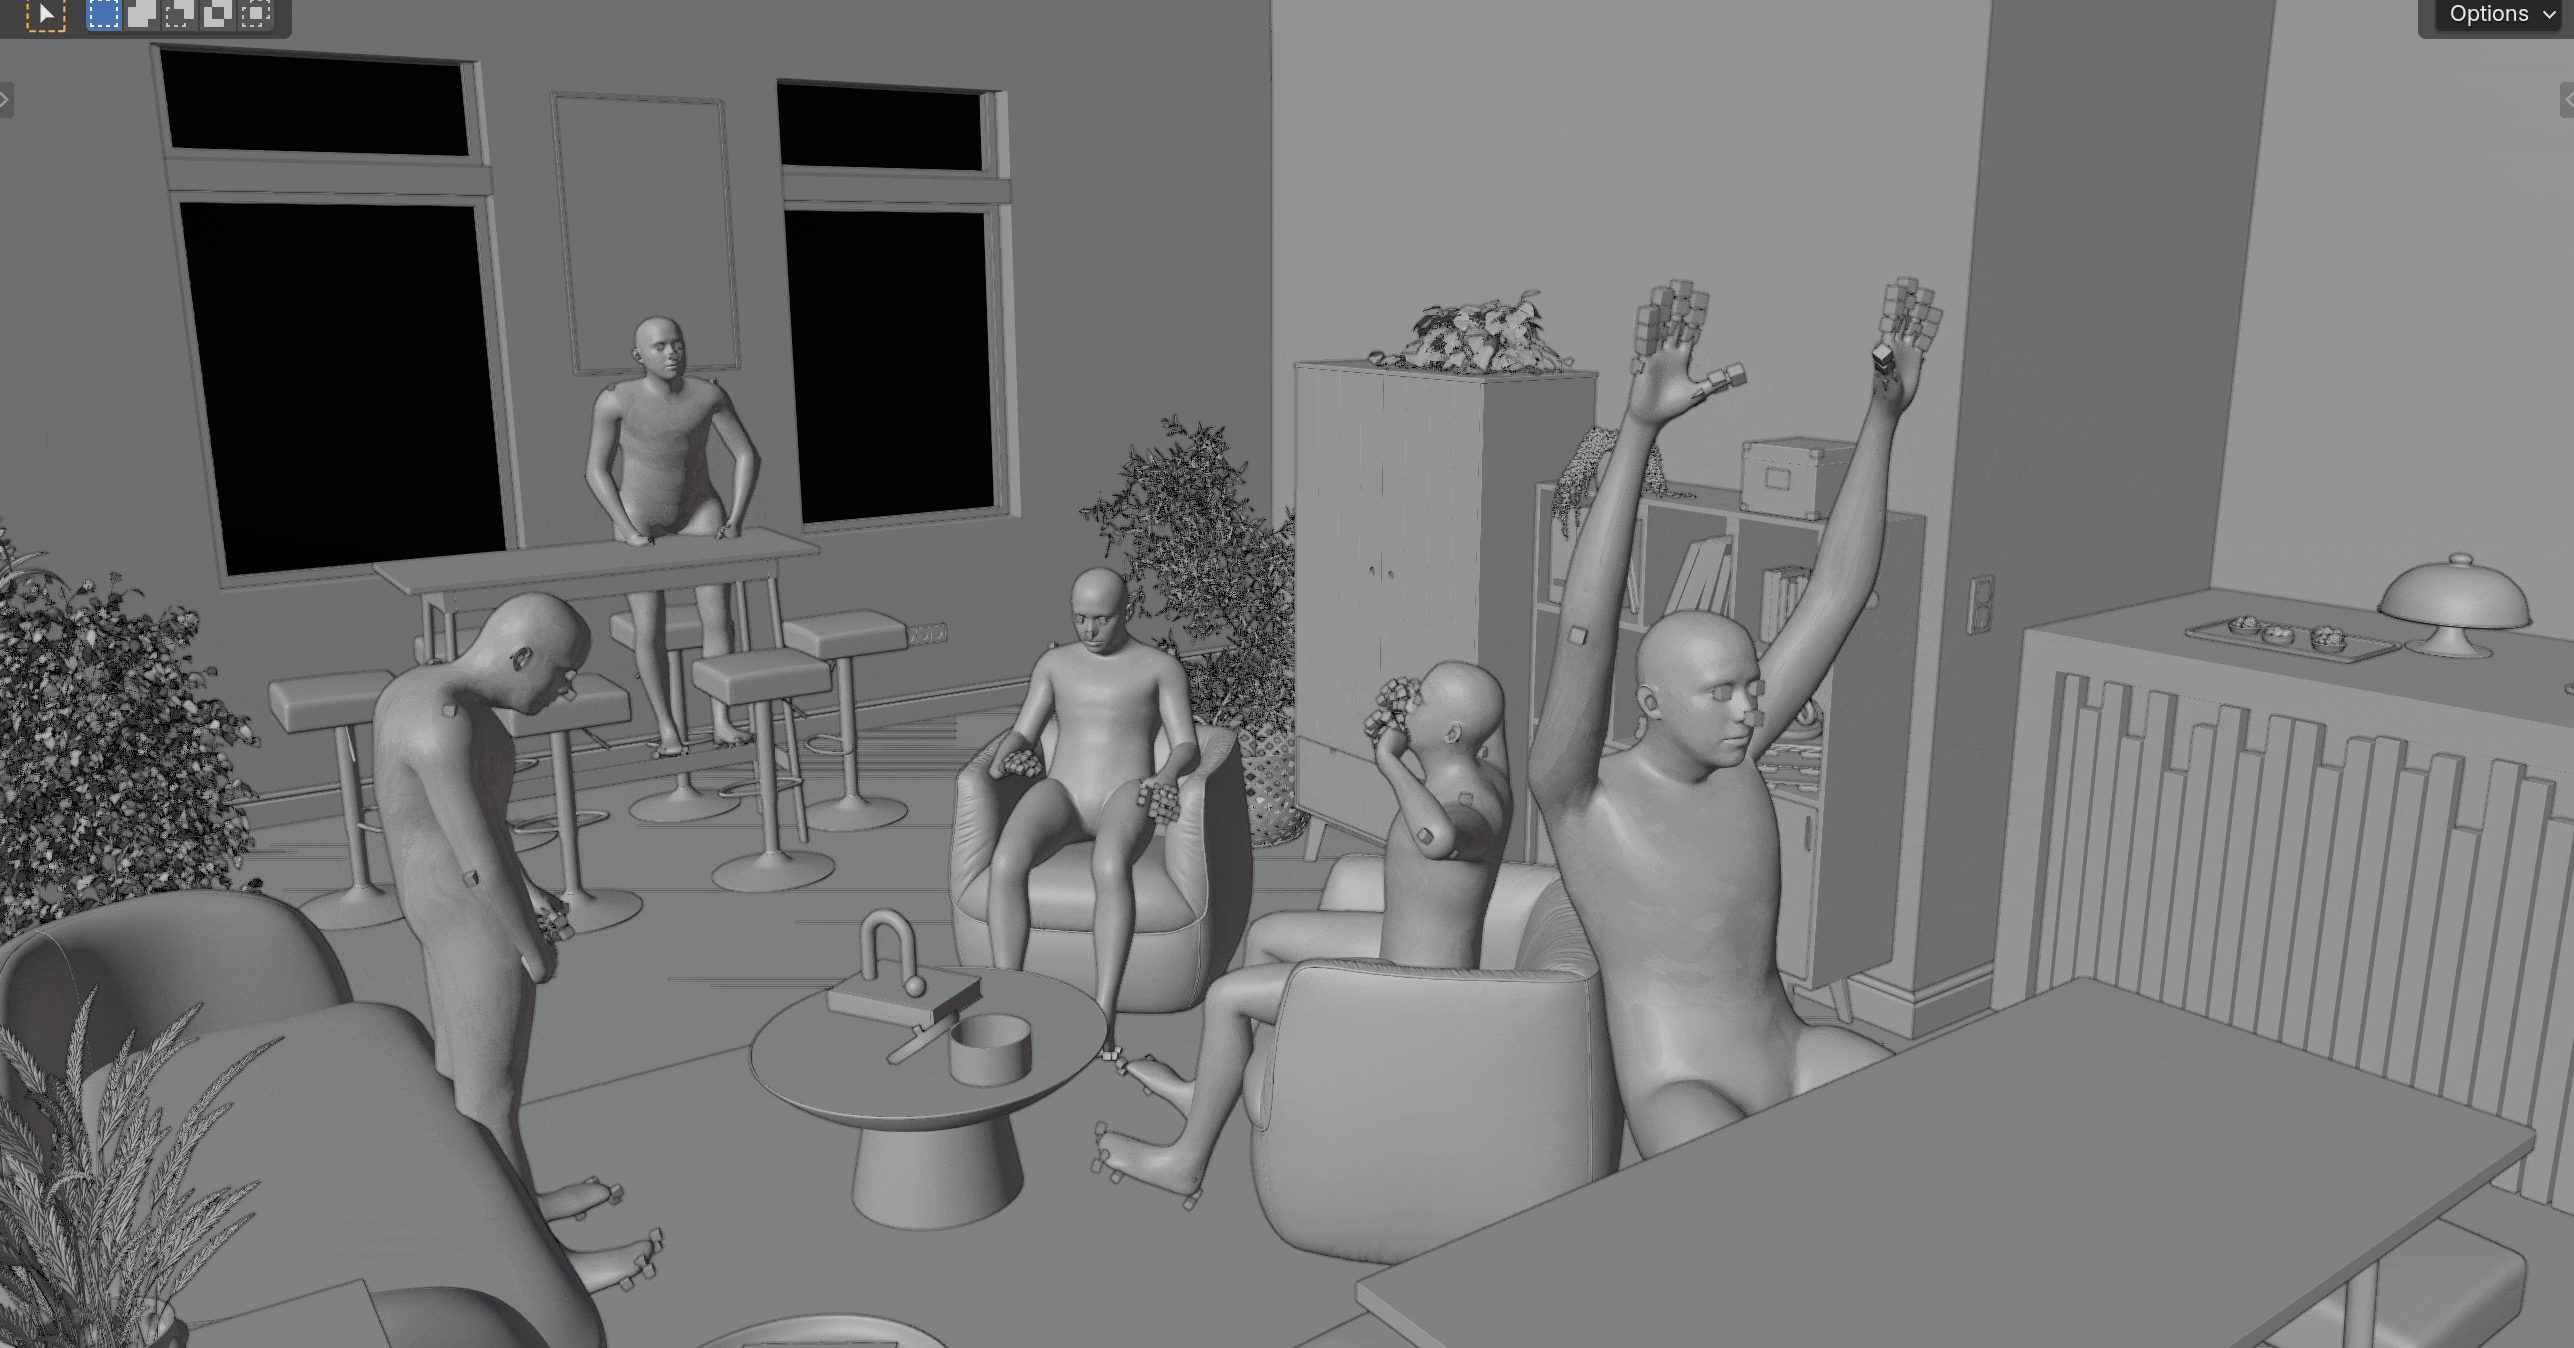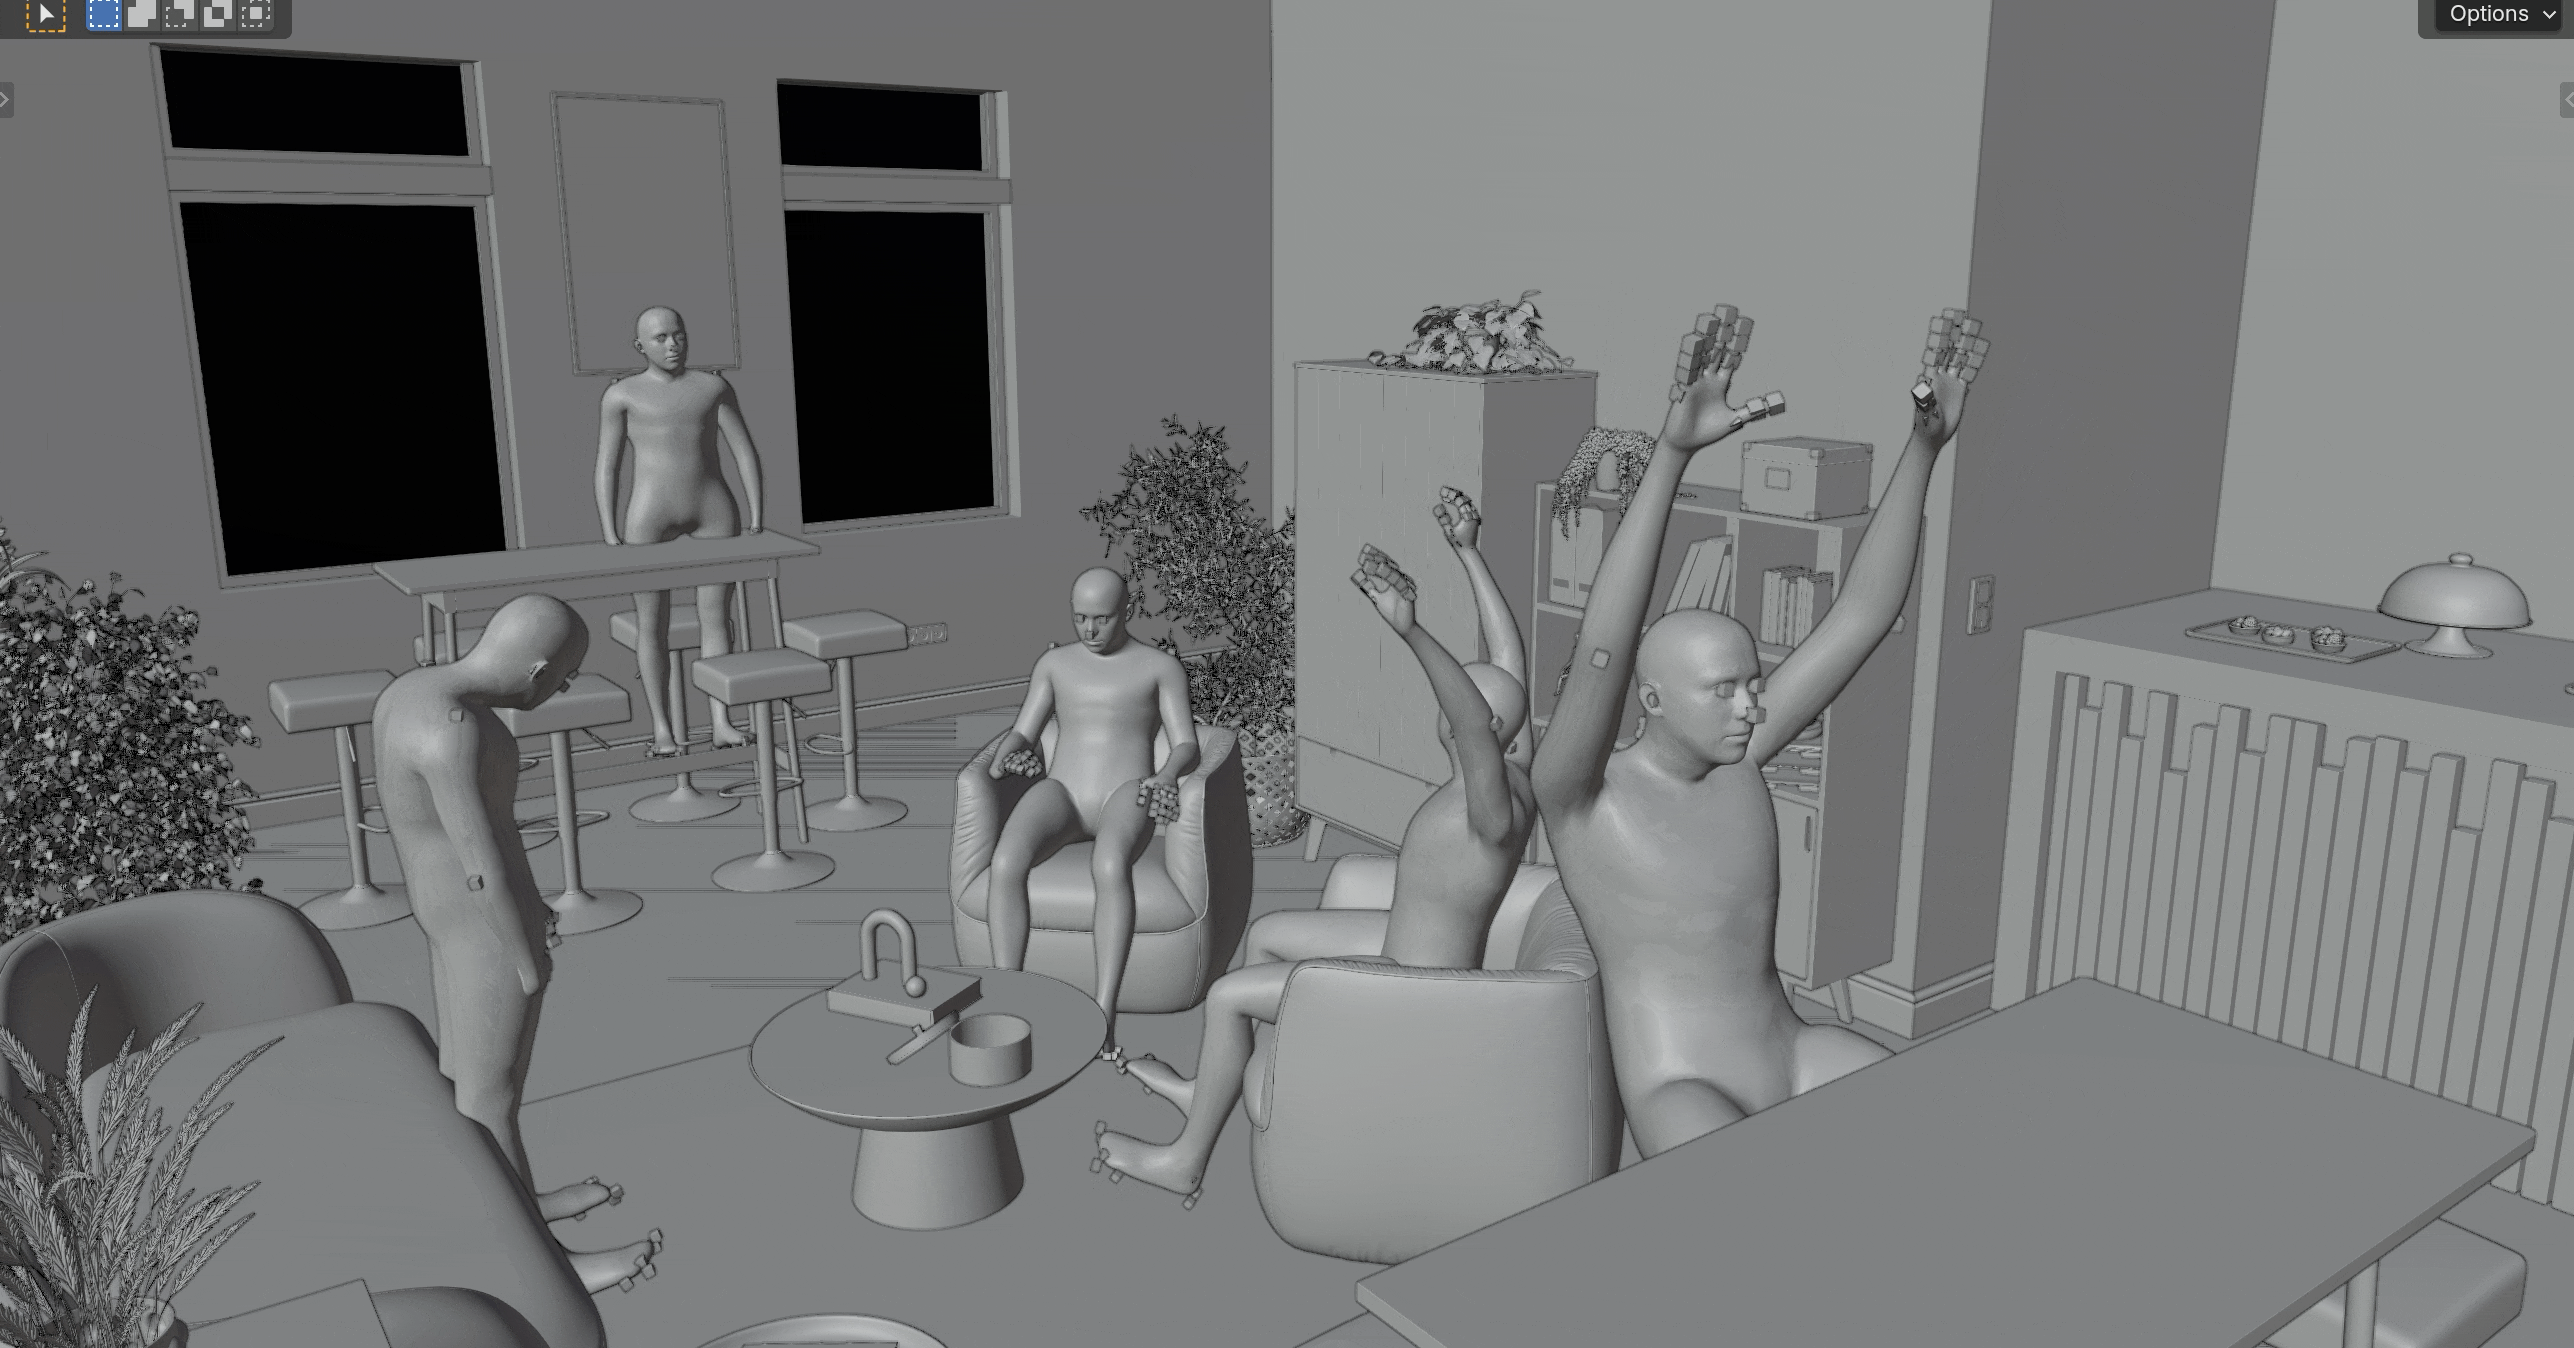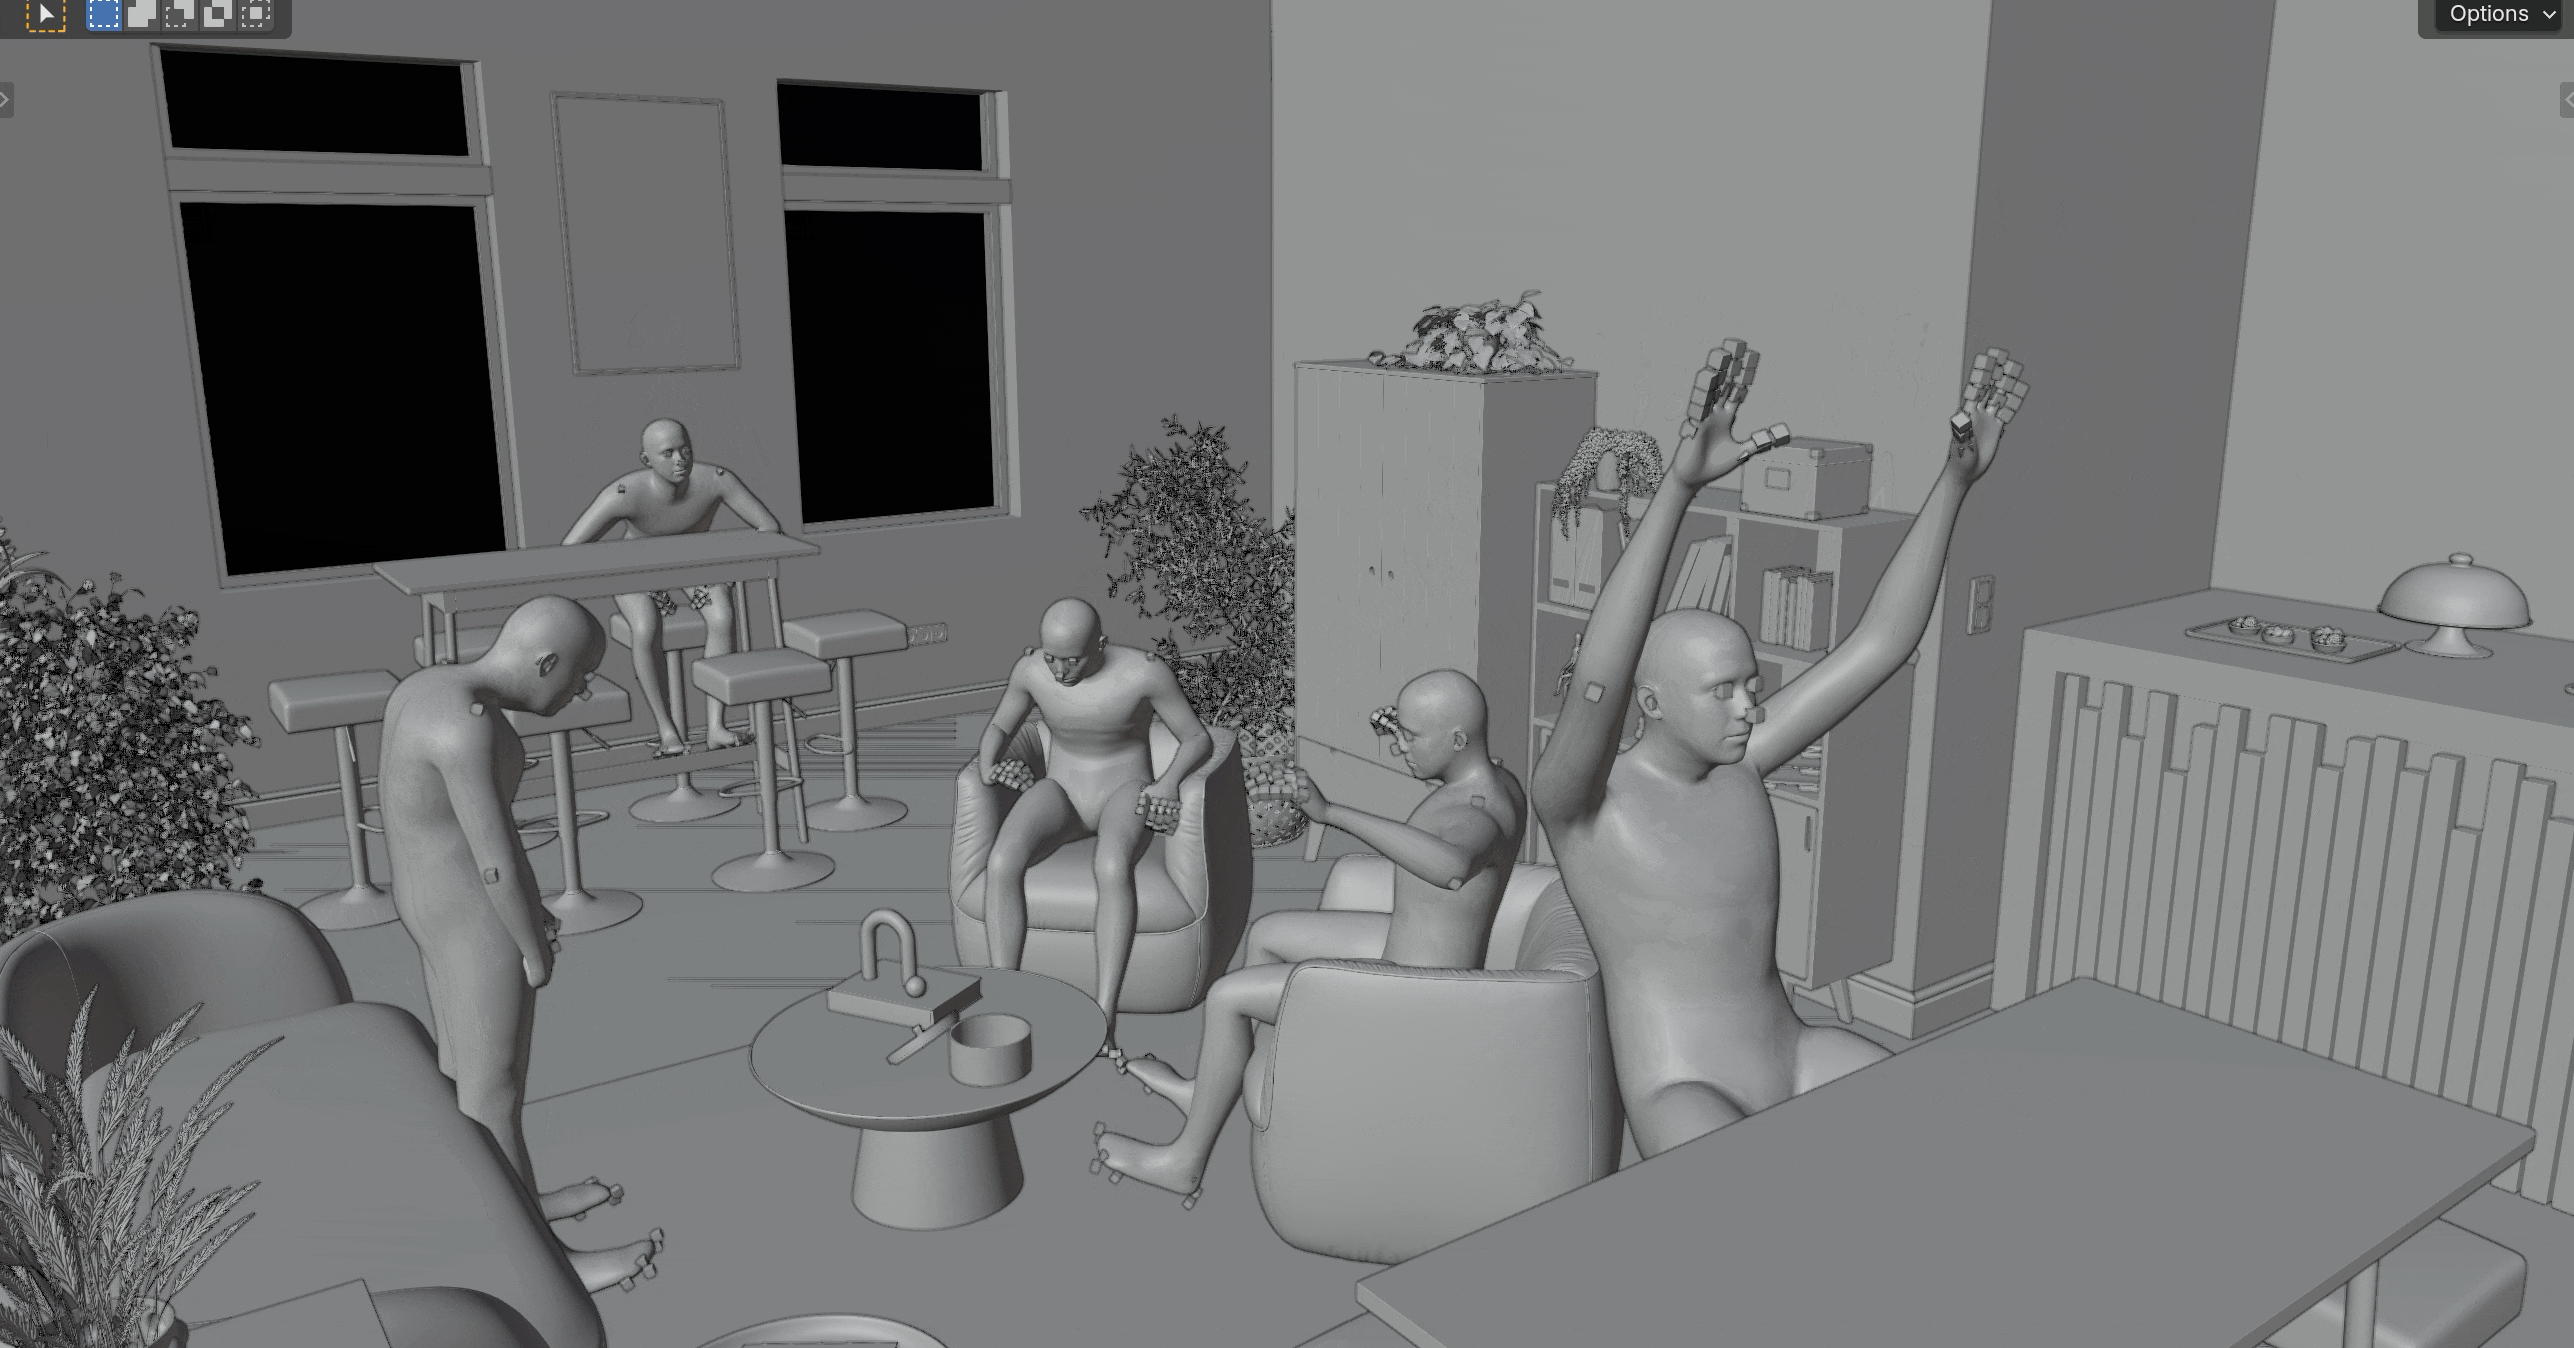
@inproceedings{liang2026seatswap,
  title={SeatSwap: Learning-Assisted Differentiable Kinematics for Human-Object Interaction Adaptation in Production-Scale Character Animation},
  author={Liang, Jasmine and Mylabathula, Stephen and Segev, Shai and Deshmukh, Priyamvad Ravindra and Liu, Ying and Aubel, Amaury},
  booktitle={Special Interest Group on Computer Graphics and Interactive Techniques Conference Posters (SIGGRAPH Posters '26)},
  year={2026},
  doi={10.1145/3799825.3818703},
  isbn={979-8-4007-2548-7},
  publisher={ACM},
  address={Los Angeles, CA, USA}
}We thank Marcelo Simoes Wolf for his direction, guidance, support, and vision; Boris Schauerte for mentorship; Chris Twigg and Carsten Stoll for rigs and model infrastructure support; and Filippo Arcadu for coordinating data sourcing—along with all the XFNs who supported this work. We are grateful to our leadership and Reality Labs for the resources that made this work possible.